CoRL2026-CSI/SO101_teleop_close_drawer_100epi_wristfix_50epi_8to2
收藏资源简介:
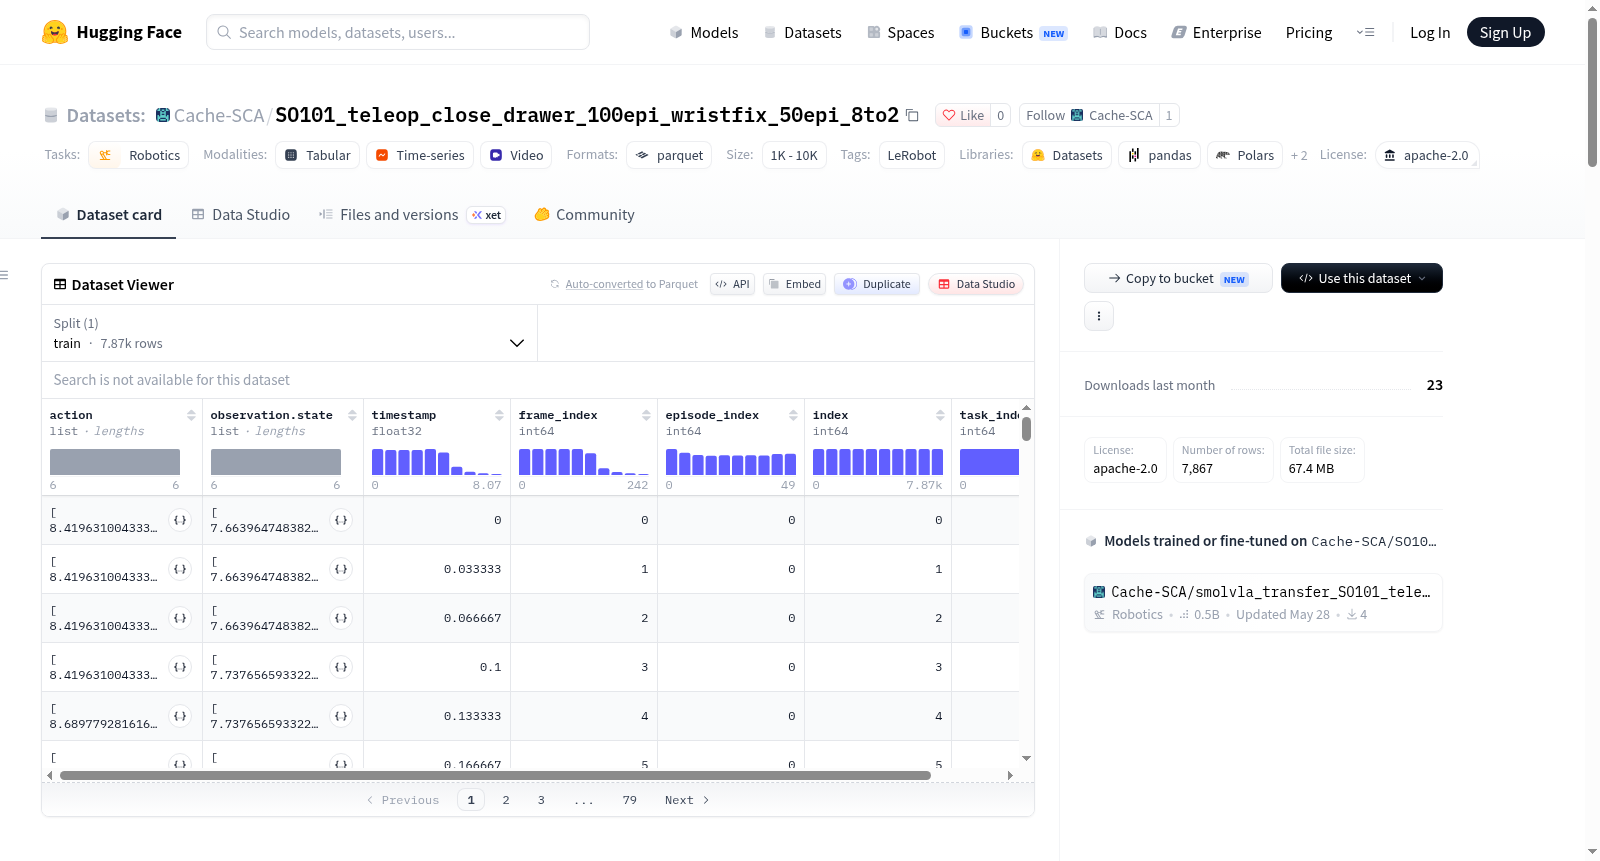
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). <a class="flex" href="https://huggingface.co/spaces/lerobot/visualize_dataset?path=CoRL2026-CSI/SO101_teleop_close_drawer_100epi_wristfix_50epi_8to2"> <img class="block dark:hidden" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl.svg"/> <img class="hidden dark:block" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl-dark.svg"/> </a> ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "robot_type": "so_follower", "total_episodes": 50, "total_frames": 7867, "total_tasks": 1, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 200, "fps": 30, "splits": { "train": "0:50" }, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "features": { "action": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.state": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.images.left_wrist": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "h264", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false } }, "observation.images.topview": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "h264", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false } }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
This dataset is a robotics dataset created using LeRobot, designed for robot control tasks. It contains 50 episodes with a total of 7867 frames at 30 fps, involving one task (likely closing a drawer). The data is stored in parquet format, with a total data file size of 100 MB and video file size of 200 MB. Features include actions (6 float values representing shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, and gripper positions), observation states (same 6 float values as actions), image observations (two videos from left wrist and topview, both with 480x640 resolution, 3 channels, encoded as h264, without audio), and metadata such as timestamp, frame index, episode index, etc. The dataset is intended for training and evaluating robot models, supporting learning control policies from visual and state information.