seriintan/rollout_testing_robotic_vision_02_20260526_160443
收藏资源简介:
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). <a class="flex" href="https://huggingface.co/spaces/lerobot/visualize_dataset?path=seriintan/rollout_testing_robotic_vision_02_20260526_160443"> <img class="block dark:hidden" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl.svg"/> <img class="hidden dark:block" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl-dark.svg"/> </a> ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "fps": 30, "features": { "action": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.state": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.images.front": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false } }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } }, "total_episodes": 1, "total_frames": 9472, "total_tasks": 1, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 200, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "robot_type": "so_follower", "splits": { "train": "0:1" } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
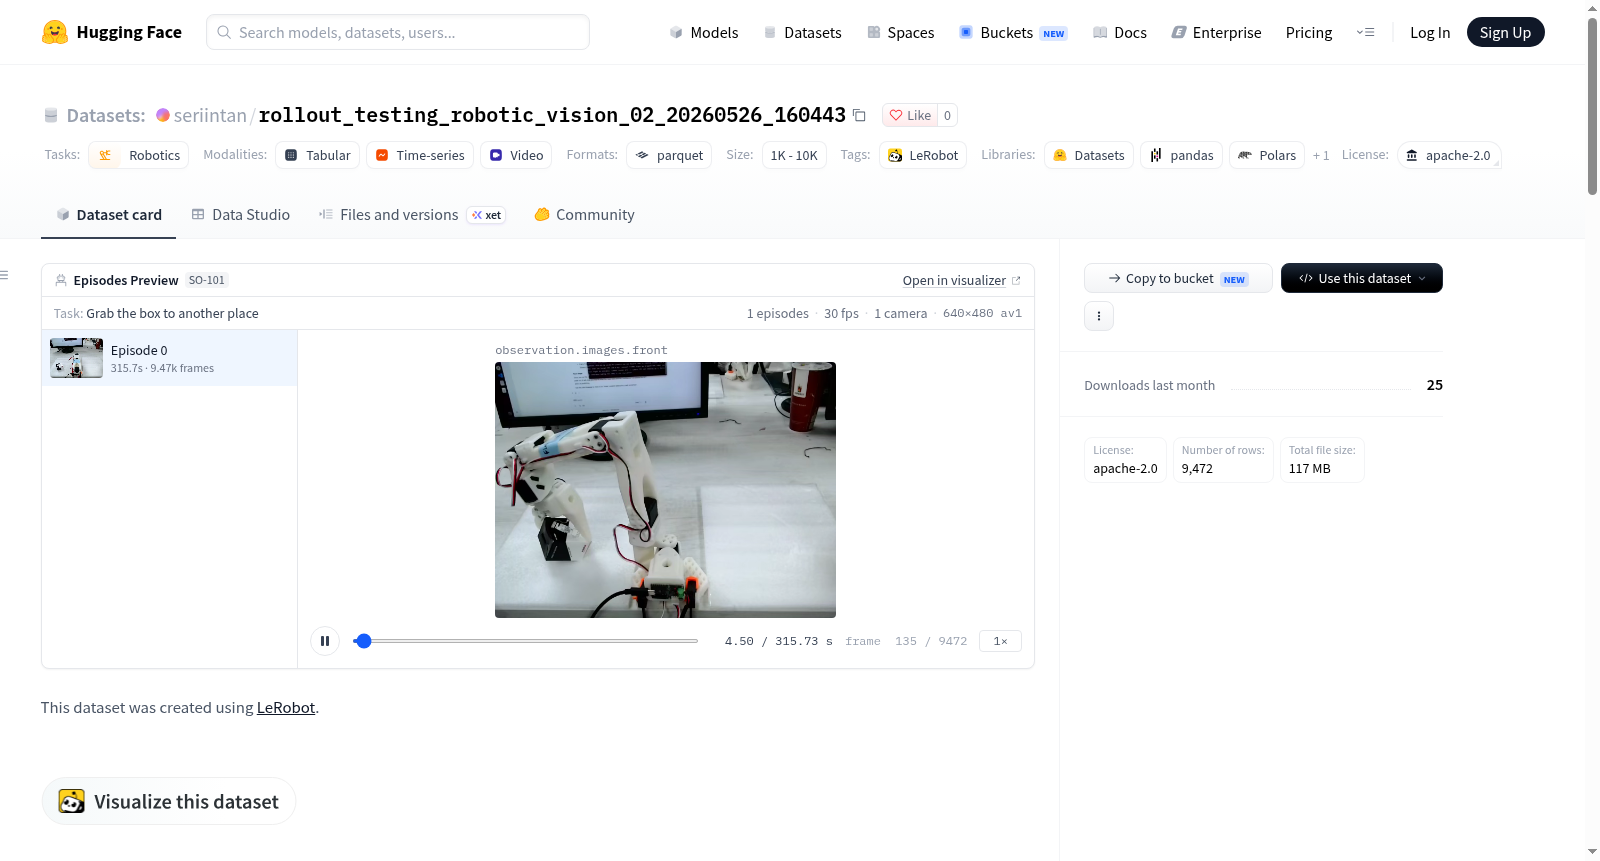
This dataset is a robotics dataset created using LeRobot. It includes robot actions and state observations, both comprising six float values for shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, and gripper positions. Observations also include video images from a front camera (resolution 480x640, 3 channels, 30fps), along with metadata such as timestamps, frame indices, and episode indices. The dataset contains 1 episode and 9472 frames in total, stored in Parquet files for data and MP4 files for videos, with a robot type of so_follower. It is designed for robotic vision-related tasks and is licensed under Apache 2.0.