eval_pi05_test_tube_ood
收藏资源简介:
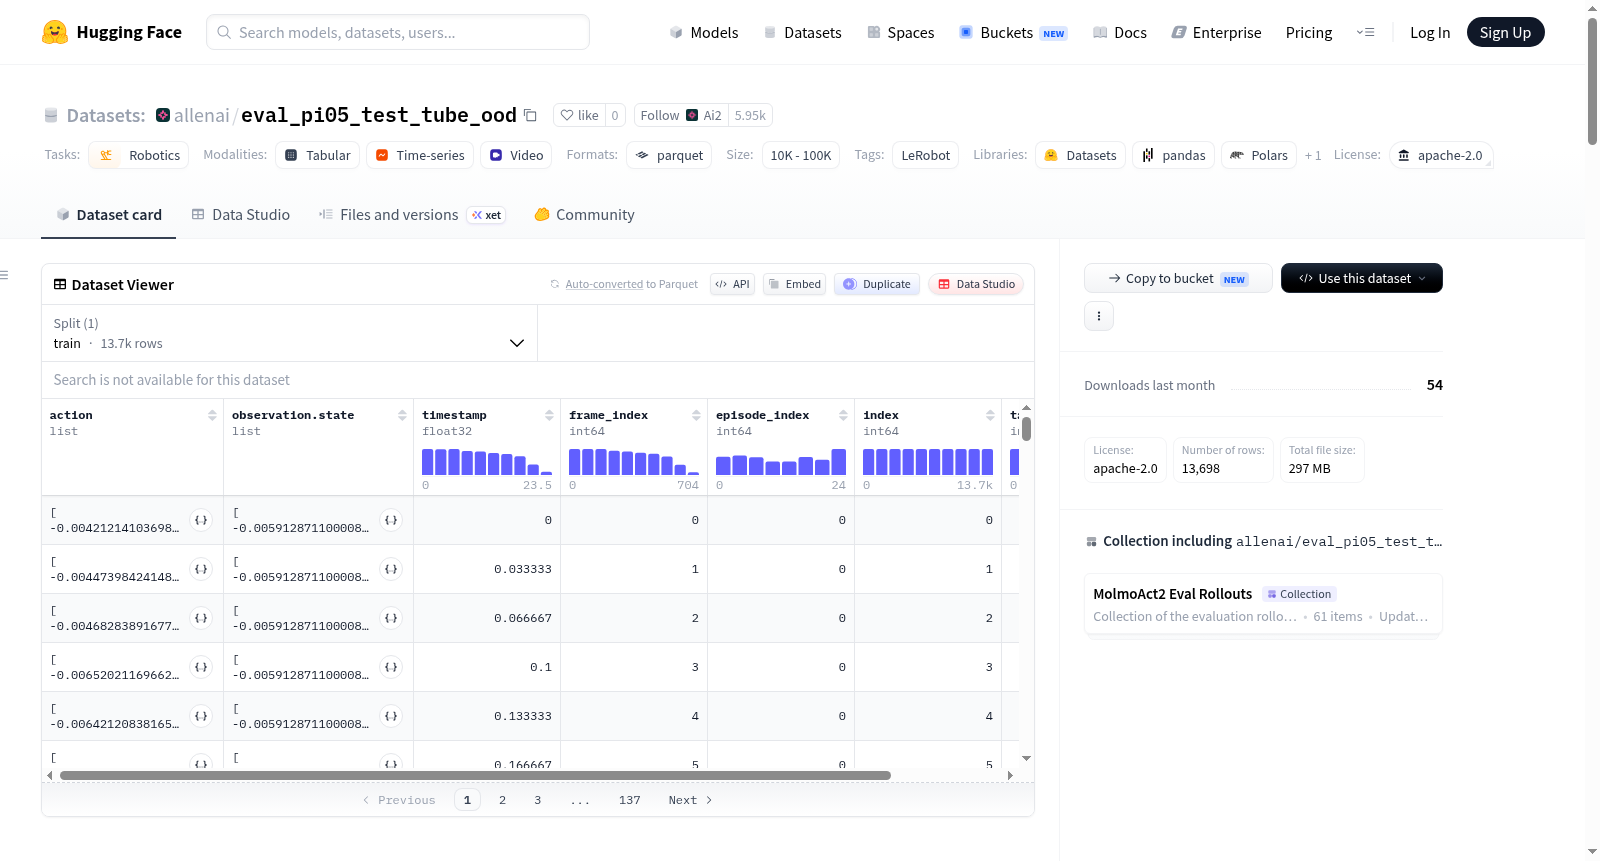
该机器人数据集使用LeRobot框架创建,专为机器人学习任务设计。数据集包含25个完整操作序列(episodes),总计13,698帧数据,涵盖3种不同的任务。数据采用多模态形式存储:结构化数据以Parquet格式保存(约100MB),包含机器人的动作指令、关节状态观测和元数据;同时提供对应的多视角视频文件(约200MB,MP4格式,AV1编码,30fps)。核心数据特征包括:14维的动作空间(控制左右机械臂各6个关节和夹爪的位置)、14维的状态观测空间(与动作空间对应)、以及来自三个固定视角(右、左、顶部)的RGB视觉观测,每个视频帧分辨率为360x640。此外,数据集还记录了时间戳、帧索引、episode索引和任务索引等元信息。该数据集适用于机器人模仿学习、强化学习、多模态感知与控制等研究领域,目前仅提供训练集划分。
This robotic dataset was created using the LeRobot framework, specifically designed for robotic learning tasks. It contains 25 complete operational episodes, totaling 13,698 frames of data, covering three distinct tasks. The data is stored in multimodal formats: structured data is saved in Parquet format (approximately 100MB), including robot action commands, joint state observations, and metadata; corresponding multi-view video files (approximately 200MB, in MP4 format with AV1 encoding, 30fps) are also provided. Core data features include: a 14-dimensional action space (controlling the positions of 6 joints and the gripper for each of the left and right robotic arms), a 14-dimensional state observation space (corresponding to the action space), and RGB visual observations from three fixed viewpoints (right, left, top), with each video frame having a resolution of 360x640. Additionally, the dataset records metadata such as timestamps, frame indices, episode indices, and task indices. This dataset is applicable to research fields including robotic imitation learning, reinforcement learning, multimodal perception and control, and only the training set split is currently provided.