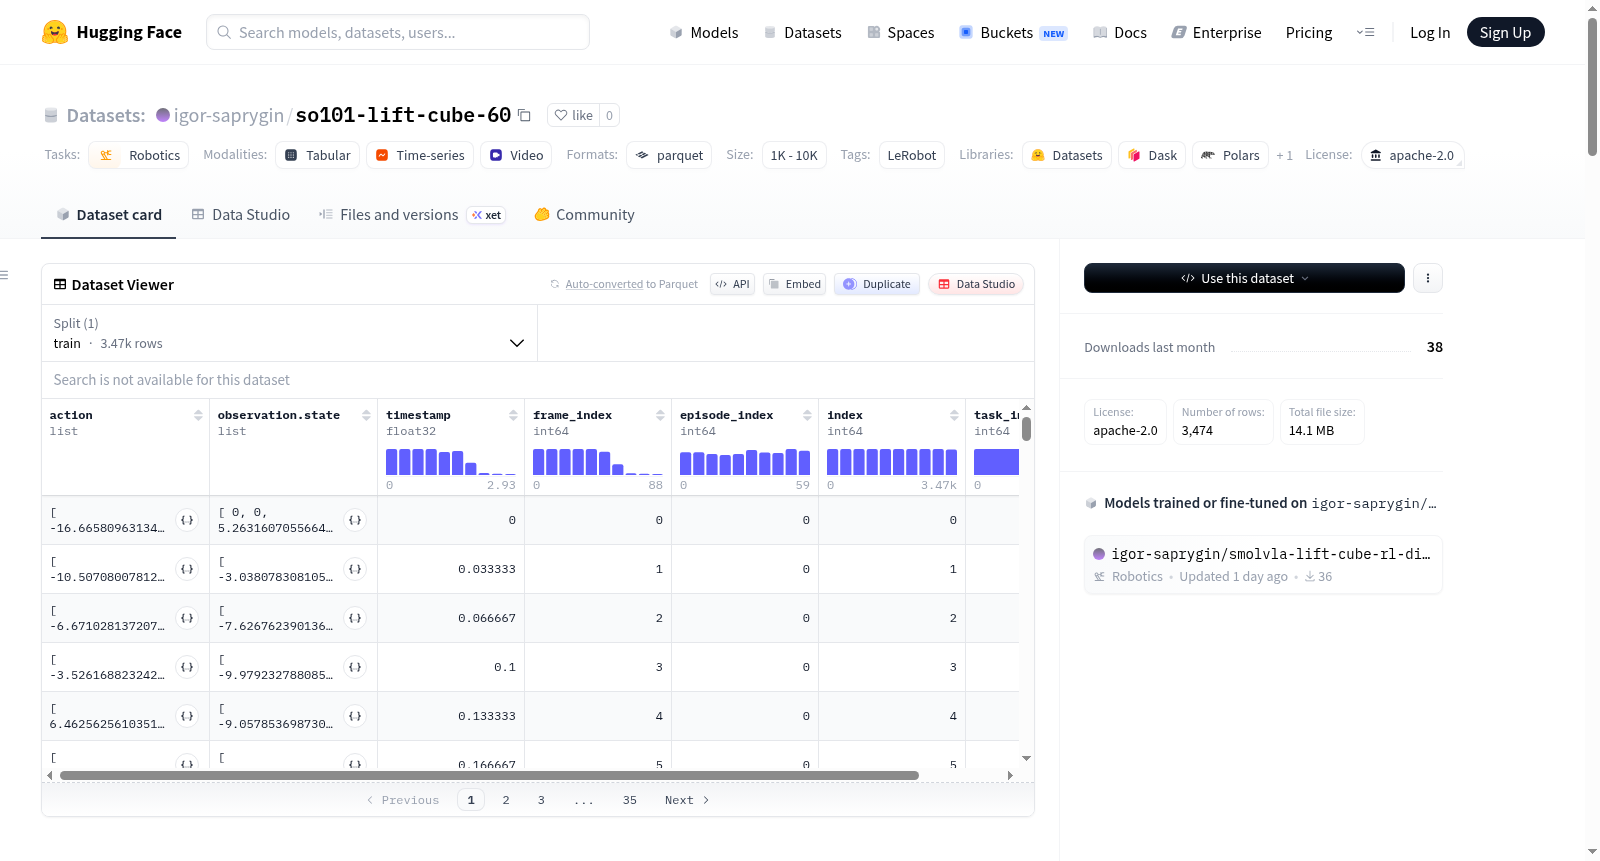
so101-lift-cube-60
收藏资源简介:
该数据集是为机器人学任务设计的,特别针对so101_follower机器人类型。数据集包含60个片段,总计2710帧,涉及1个任务。数据以parquet文件形式存储,总大小为300MB(数据文件100MB,视频文件200MB)。数据集包含丰富的特征,如动作和观察状态(各6个浮点数值),以及来自手腕和前摄像头的视频观察(分辨率480x640,AV1编码,30fps)。视频数据不包含音频。数据集还包含时间戳、帧索引、片段索引等辅助信息。适用于机器人控制、行为模仿等研究场景。
This dataset is designed for robotics tasks, specifically targeting the so101_follower robot type. It consists of 60 segments, totaling 2710 frames, covering one single task. All data is stored in Parquet files, with a total size of 300 MB (100 MB for data files and 200 MB for video files). The dataset includes rich features, such as action and observation states (each with 6 floating-point values), as well as video observations from the wrist and front-facing cameras (resolution: 480x640, AV1-encoded, 30 fps). No audio is included in the video data. The dataset also contains auxiliary information such as timestamps, frame indices, and segment indices. It is suitable for research scenarios such as robot control and behavior cloning.
数据集概述
so101-lift-cube-60 是一个用于机器人操作的 数据集,基于 LeRobot 框架创建。该数据集记录了 so101_follower 机器人执行 提升立方体 任务的动作和观测数据,共包含 60 个片段。
数据集规格
- 总片段数: 60
- 总帧数: 2,710
- 总任务数: 1
- 帧率 (FPS): 30
- 数据文件大小: 100 MB (Parquet 格式)
- 视频文件大小: 200 MB (MP4 格式)
- 分块大小: 1,000 帧/块
- 数据划分: 全部 60 个片段用于训练 (
train: 0:60)
数据结构
数据集包含以下特征(features):
动作 (action)
- 数据类型: float32
- 形状: [6]
- 维度名称:
shoulder_pan.pos,shoulder_lift.pos,elbow_flex.pos,wrist_flex.pos,wrist_roll.pos,gripper.pos
观测状态 (observation.state)
- 数据类型: float32
- 形状: [6]
- 维度名称: 与动作相同,表示机器人各关节位置
观测图像 (observation.images)
observation.images.wrist: 腕部摄像头图像- 分辨率: 480×640 像素,3 通道 (RGB)
- 编码: AV1,帧率 30 FPS
observation.images.front: 前方摄像头图像- 分辨率: 480×640 像素,3 通道 (RGB)
- 编码: AV1,帧率 30 FPS
其他字段
timestamp(float32): 时间戳frame_index(int64): 帧索引episode_index(int64): 片段索引index(int64): 全局索引task_index(int64): 任务索引
数据存储
- 数据文件: 存储在
data/目录下,格式为chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频文件: 存储在
videos/目录下,格式为videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4
许可证
- 许可证类型: Apache-2.0