eval_xvla_test_tube_ood
收藏资源简介:
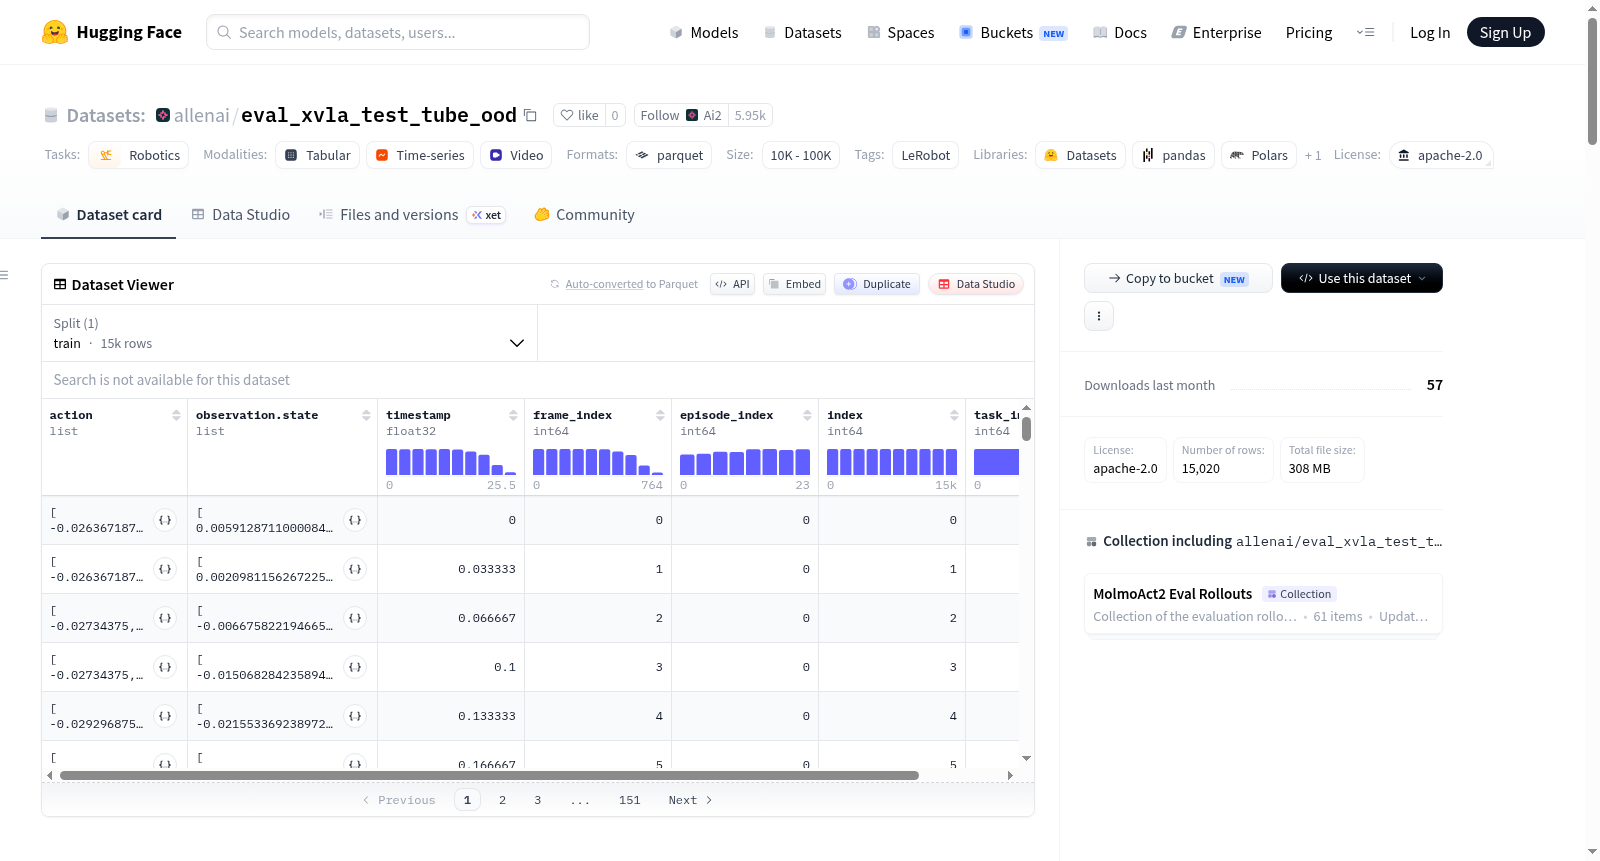
该数据集是一个机器人任务演示数据集,使用LeRobot工具创建,来自名为bi_yam_follower的双机器人系统。数据集包含24个完整的演示片段,共计15020个数据帧,覆盖3个不同任务,仅划分为训练集。数据以分块形式存储(每块1000帧),总大小约100MB,关联视频总大小约200MB,帧率为30 FPS。核心内容是多模态机器人交互数据,包括:1) `action`:14维浮点向量,表示左、右机械臂的6个关节位置和1个夹爪位置的动作指令;2) `observation.state`:14维浮点向量,表示当前时刻的关节与夹爪位置状态观测;3) `observation.images`:来自右、左、顶三个固定视角的视觉观测,每个视角视频分辨率为640x360,3通道彩色,采用AV1编码;4) 元数据字段:如`timestamp`、`frame_index`、`episode_index`、`index`和`task_index`。适用于机器人模仿学习、视觉运动策略学习和多模态感知与控制等研究任务。
This dataset is a robot task demonstration dataset created using the LeRobot tool, derived from a dual-robot system named bi_yam_follower. It contains 24 complete demonstration episodes, totaling 15,020 data frames, covering 3 different tasks, and is divided only into a training split. The data is stored in chunks (each with 1,000 frames), with a total size of approximately 100MB, and associated video files totaling about 200MB at a frame rate of 30 FPS. The core content consists of multimodal robot interaction data, including: 1) `action`: a 14-dimensional floating-point vector representing action commands for the left and right robotic arms 6 joint positions and 1 gripper position; 2) `observation.state`: a 14-dimensional floating-point vector representing state observations of joint and gripper positions at the current moment; 3) `observation.images`: visual observations from three fixed perspectives (right, left, top), with each views video resolution at 640x360, 3-channel color, encoded in AV1; 4) metadata fields: such as `timestamp`, `frame_index`, `episode_index`, `index`, and `task_index`. It is suitable for research tasks like robot imitation learning, visual-motor policy learning, and multimodal perception and control.