language_table_train_107000_108000_augmented
收藏资源简介:
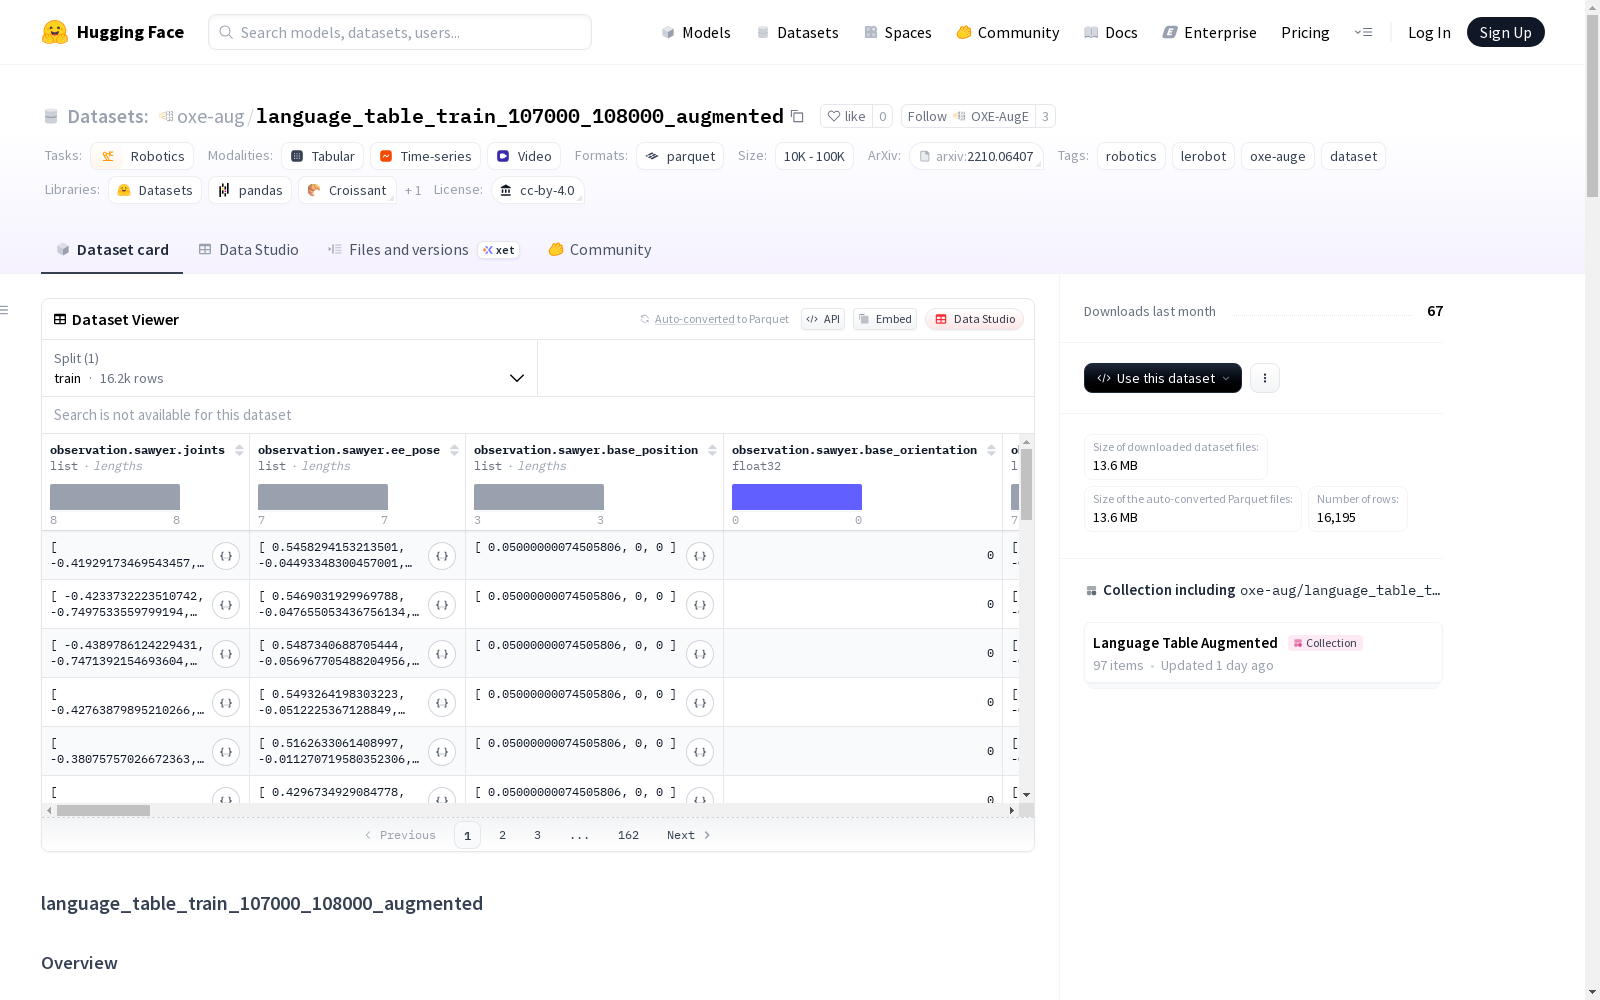
language_table_train_107000_108000_augmented是一个机器人增强数据集,包含了google_robot、images、jaco、kinova3、kuka_iiwa、panda、sawyer和ur5e等多种机器人的增强图像、位置和关节角度等信息。数据集共1000个剧集,总帧数为16195帧,分为训练集。数据集特征包括增强图像、末端执行器位置、误差、关节角度以及自然语言指令。
language_table_train_107000_108000_augmented is a robotic augmented dataset that contains augmented images, positions, joint angles and other information of various robots including google_robot, images, jaco, kinova3, kuka_iiwa, panda, sawyer and ur5e. The dataset comprises 1000 episodes with a total of 16195 frames, and is partitioned into the training set. The dataset features include augmented images, end-effector positions, errors, joint angles as well as natural language instructions.
language_table_train_107000_108000_augmented 数据集概述
基本信息
- 数据集名称: language_table_train_107000_108000_augmented
- 许可证: CC-BY-4.0
- 代码库版本: v3.0
- 任务类别: 机器人学
- 标签: 机器人学, lerobot, oxe-auge, dataset
数据集规模
- 总片段数: 1,000
- 总帧数: 16,195
- 帧率: 10 FPS
- 数据分割:
- 训练集: 1,000个片段
机器人类型
支持以下8种机器人平台:
- google_robot
- images
- jaco
- kinova3
- kuka_iiwa
- panda
- sawyer
- ur5e
数据特征
图像特征
所有机器人图像特征均为360×640×3分辨率的视频数据:
observation.images.google_robot: Google机器人增强图像observation.images.image: 原始数据集中的源机器人图像observation.images.jaco: Jaco机器人增强图像observation.images.kinova3: Kinova3机器人增强图像observation.images.kuka_iiwa: Kuka IIWA机器人增强图像observation.images.panda: Panda机器人增强图像observation.images.sawyer: Sawyer机器人增强图像observation.images.ur5e: UR5e机器人增强图像
机器人状态特征
每个机器人类型包含以下状态信息:
base_orientation: 绕Z轴逆时针旋转角度base_position: 基座平移位置ee_error: 增强机器人与原始机器人末端执行器误差ee_pose: 末端执行器位姿joints: 关节位置
元数据特征
episode_index: 片段索引frame_index: 帧索引index: 全局帧索引natural_language_instruction: 自然语言指令task_index: 任务IDtimestamp: 时间戳
数据布局
- 数据路径:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频路径:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4
相关资源
- 项目网站: https://oxe-auge.github.io/
- 代码仓库: https://github.com/GuanhuaJi/oxe-auge
- 相关论文: https://arxiv.org/abs/2210.06407
引用要求
使用本数据集时需同时引用OXE-AugE数据集和上游原始数据集。