eii-pick-battery-droid
收藏资源简介:
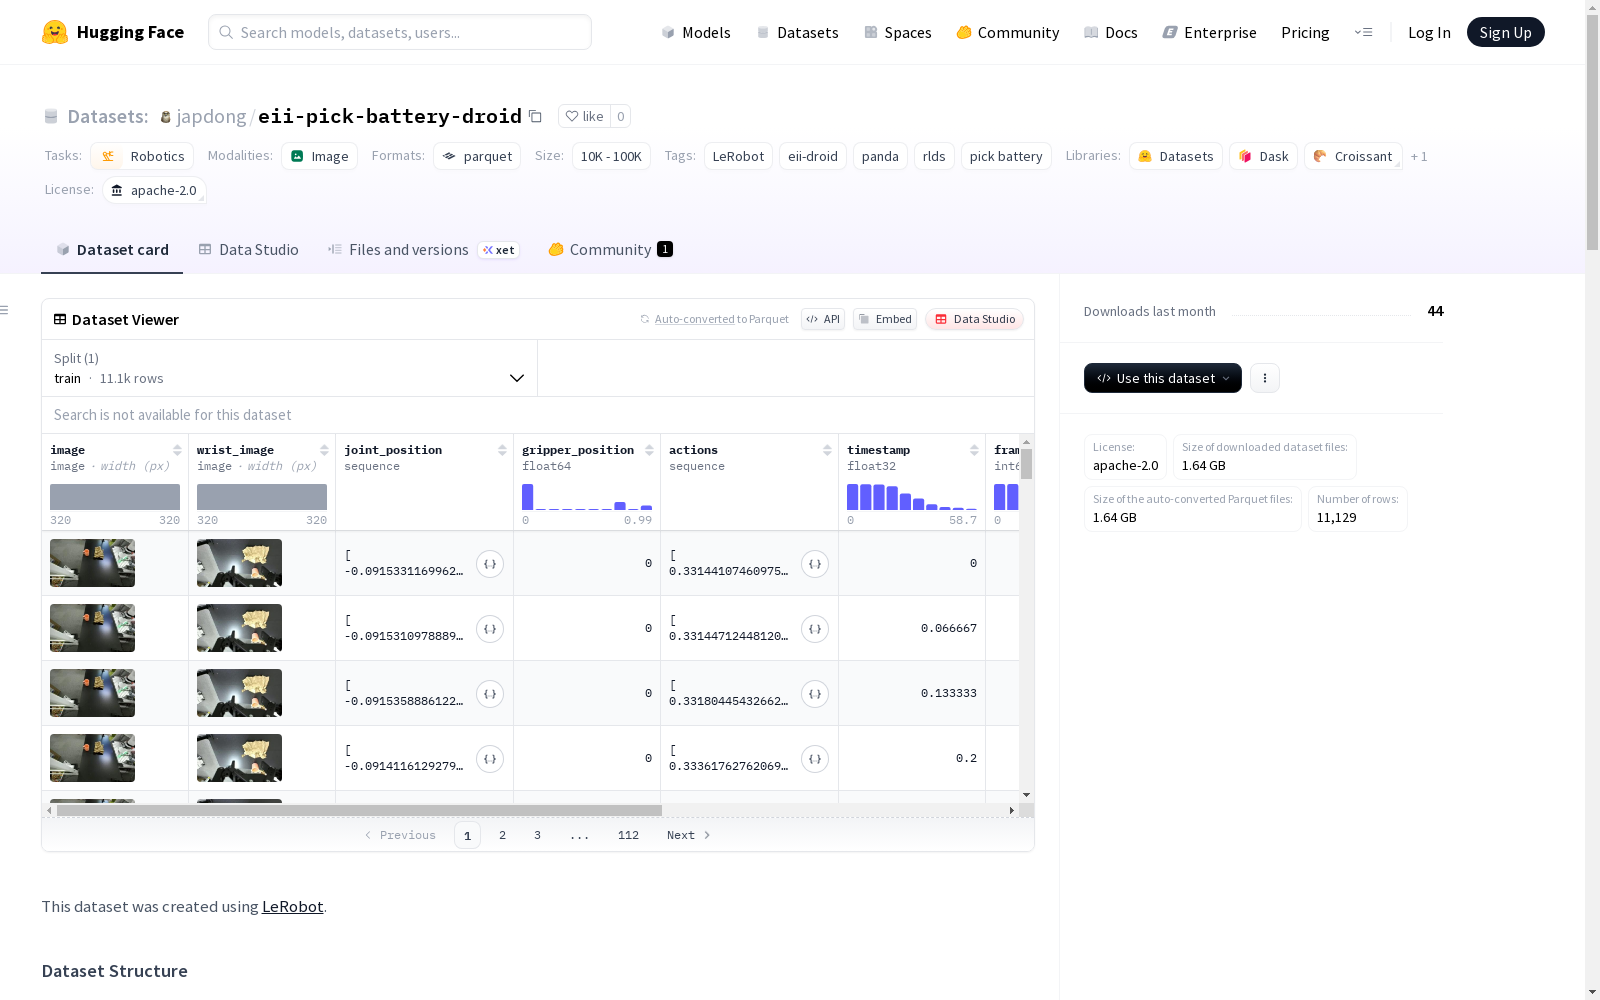
该数据集与机器人学相关,特别是针对Panda机器人。它包含了关于剧集、帧和任务的信息,以及关于数据路径和视频路径的详细资料。数据集特征包括图像、关节位置、夹爪位置、动作和时间戳等。该数据集遵循Apache-2.0许可证,使用LeRobot创建。不过,数据集的描述和引用信息标明需要更多信息,README文件中未直接提供数据集的描述。
This dataset is associated with robotics, with a specific focus on the Panda robot. It encompasses information related to episodes, frames, and tasks, alongside detailed records of data paths and video paths. The dataset features include images, joint positions, gripper positions, actions, and timestamps, amongst others. Licensed under the Apache-2.0 license, this dataset was developed using LeRobot. Nevertheless, the dataset's description and citation notes indicate that additional information is needed, as the README file does not directly provide the dataset's official description.
数据集概述
基本信息
- 名称: japdong/eii-pick-battery-droid
- 许可证: apache-2.0
- 任务类别: robotics
- 标签: LeRobot, eii-droid, panda, rlds, pick battery
数据集描述
- 创建工具: LeRobot
- 主页: [More Information Needed]
- 论文: [More Information Needed]
数据集结构
- 配置名称: default
- 数据文件: data//.parquet
- 元数据文件: meta/info.json
元数据详情
- 代码库版本: v2.0
- 机器人类型: panda
- 总剧集数: 23
- 总帧数: 11129
- 总任务数: 1
- 总视频数: 0
- 总块数: 1
- 块大小: 1000
- 帧率: 15 fps
- 数据分割:
- 训练集: 0:23
- 数据路径: data/chunk-{episode_chunk:03d}/episode_{episode_index:06d}.parquet
- 视频路径: videos/chunk-{episode_chunk:03d}/{video_key}/episode_{episode_index:06d}.mp4
特征
- image:
- 数据类型: image
- 形状: [180, 320, 3]
- 维度名称: height, width, channel
- wrist_image:
- 数据类型: image
- 形状: [180, 320, 3]
- 维度名称: height, width, channel
- joint_position:
- 数据类型: float64
- 形状: [7]
- 维度名称: joint_position
- gripper_position:
- 数据类型: float64
- 形状: [1]
- 维度名称: gripper_position
- actions:
- 数据类型: float64
- 形状: [7]
- 维度名称: actions
- timestamp:
- 数据类型: float32
- 形状: [1]
- frame_index:
- 数据类型: int64
- 形状: [1]
- episode_index:
- 数据类型: int64
- 形状: [1]
- index:
- 数据类型: int64
- 形状: [1]
- task_index:
- 数据类型: int64
- 形状: [1]
引用
- BibTeX: [More Information Needed]