rslxcvg/task2_v4
收藏资源简介:
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). <a class="flex" href="https://huggingface.co/spaces/lerobot/visualize_dataset?path=rslxcvg/task2_v4"> <img class="block dark:hidden" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl.svg"/> <img class="hidden dark:block" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl-dark.svg"/> </a> ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "fps": 30, "features": { "action": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.state": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.images.front": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "h264", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false, "video.extra_options": {}, "video.video_backend": "pyav", "video.g": null, "video.crf": null, "video.preset": null, "video.fast_decode": null } }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } }, "total_episodes": 540, "total_frames": 224574, "total_tasks": 3, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 200, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "robot_type": "so_follower", "splits": { "train": "0:540" } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
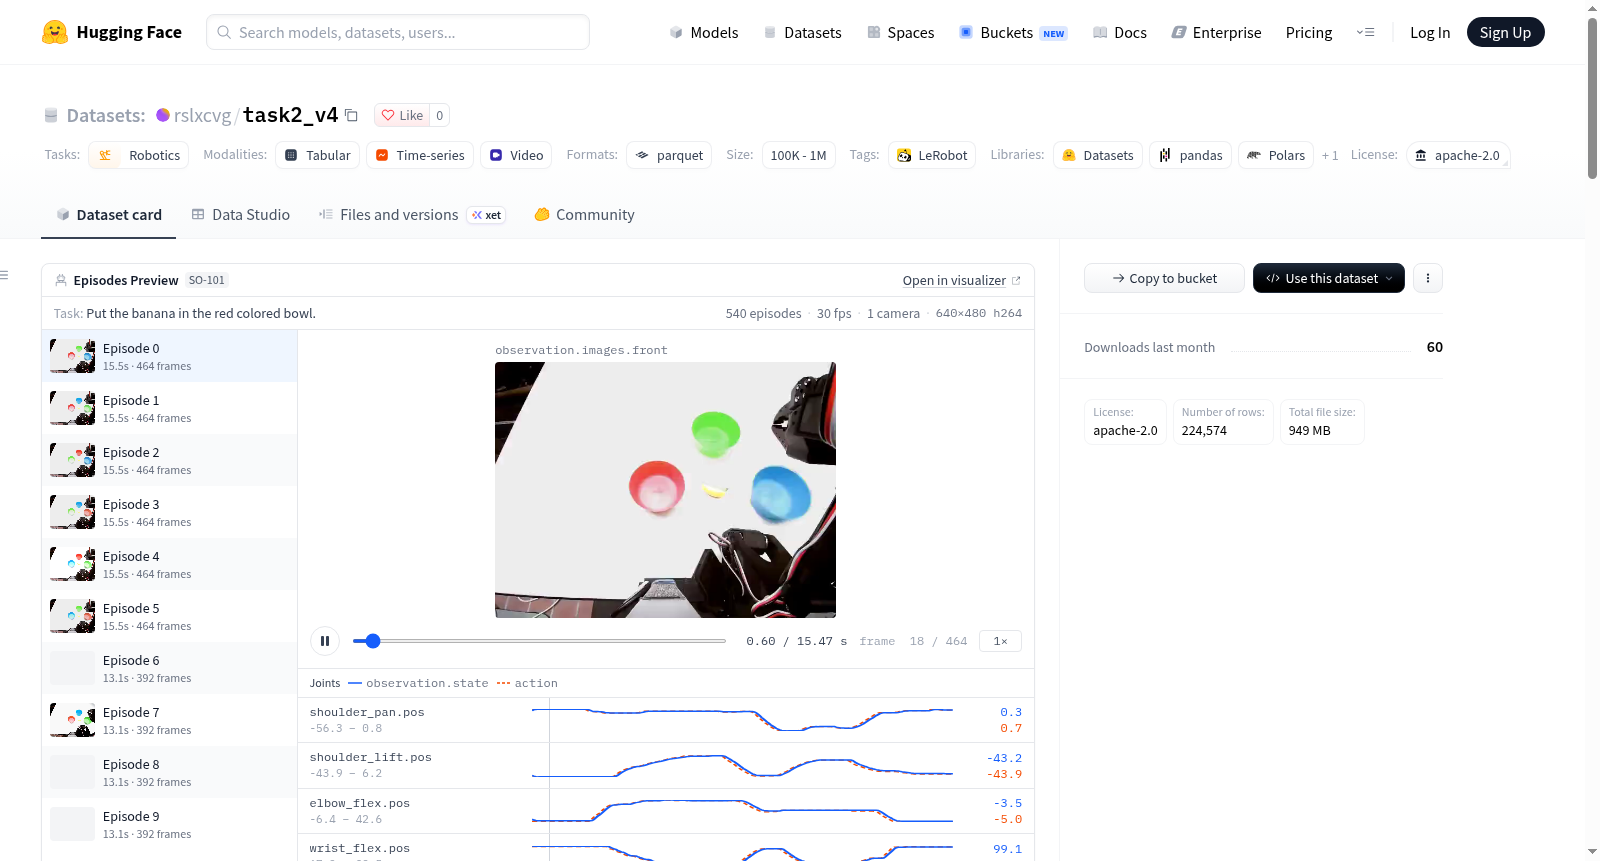
This is a robotics dataset created using the LeRobot tool, specifically designed for robot learning and control tasks. The dataset consists of 540 total episodes, totaling 224,574 frames, and covers 3 distinct tasks. The features include action and observation state, both represented in float32 format, involving robot joint positions (such as shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, and gripper positions). The observation also includes front-view images (observation.images.front) stored in video format with a resolution of 480x640, 3 channels, a frame rate of 30fps, and encoded with h264. The dataset structure additionally includes metadata such as timestamp, frame index, episode index, index, and task index. Data files are stored in Parquet format, while video files are in MP4 format. The robot type is so_follower, the dataset is licensed under Apache-2.0, and it includes a training split (all 540 episodes for training).