metaworld_mt50_push_v2_image
收藏
资源简介:
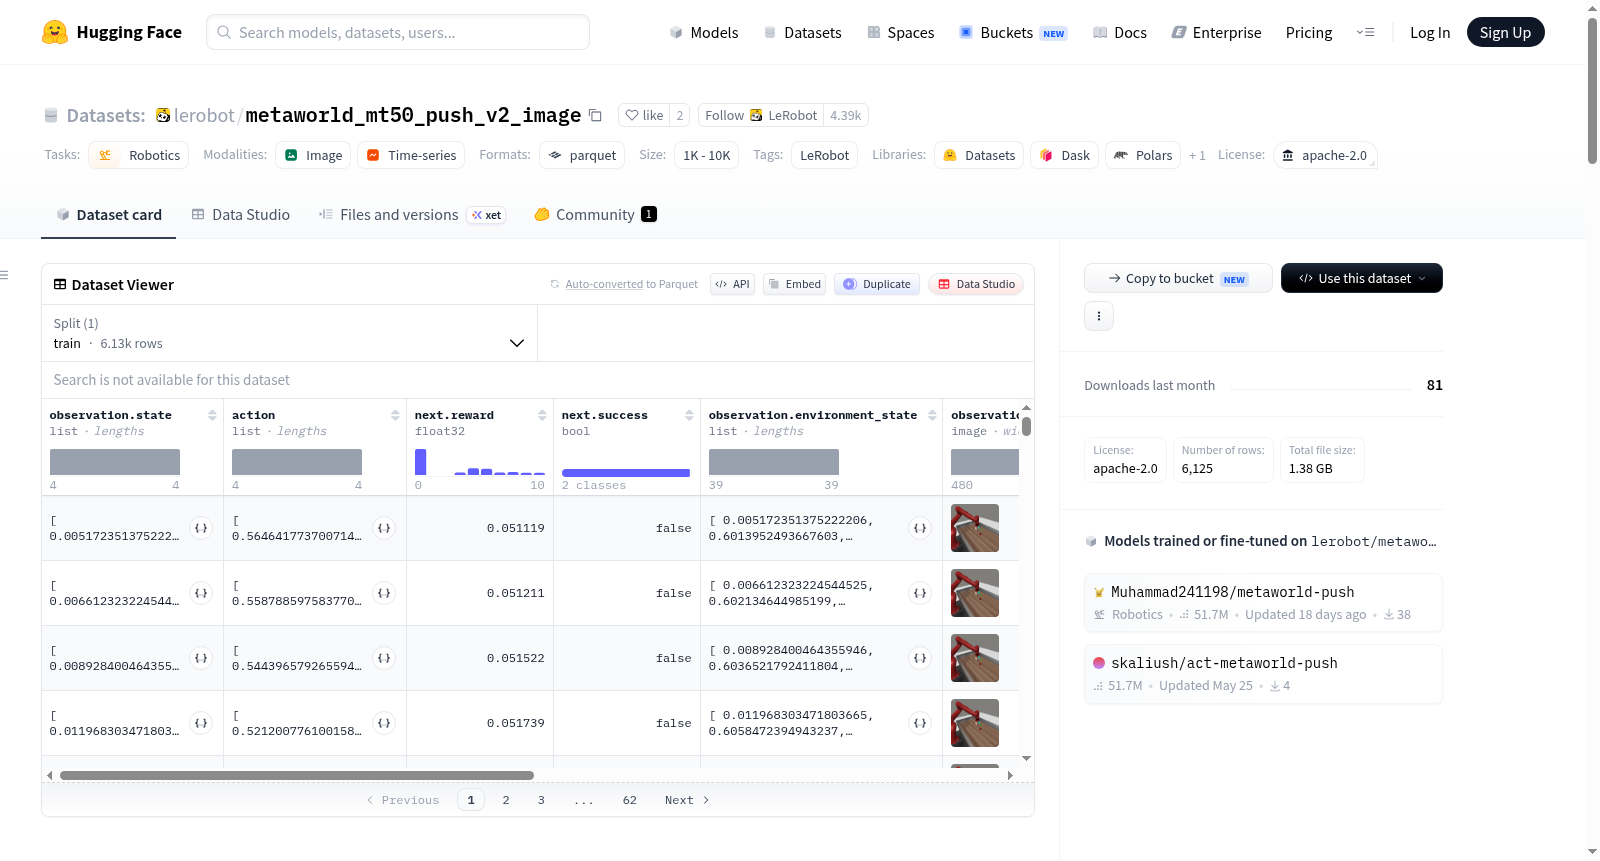
该数据集是使用LeRobot创建的,涉及机器人技术。数据集包含100个片段,6125帧,1个任务,但没有视频。数据以parquet格式存储,包含多种特征,如观察状态(4维浮点数组)、动作(4维浮点数组,包括x、y、z和夹持器)、奖励(1维浮点数组)、成功标志(布尔值)、环境状态(39维浮点数组,代表关键点)、图像(3通道480x480像素)、任务ID(整型)、时间戳(浮点型)、帧索引、片段索引、索引和任务索引。数据集的帧率为80fps,并包含训练分割(0:100)。此外,还对相机位置进行了调整和图像翻转。
This dataset was developed using LeRobot for robotics-related research and applications. It comprises 100 episodes, 6125 frames, and targets a single task, with no video data included. The data is stored in Parquet format and encompasses a variety of features: observation states (4-dimensional floating-point arrays), actions (4-dimensional floating-point arrays covering x, y, z, and gripper state), rewards (1-dimensional floating-point arrays), success flags (boolean values), environment states (39-dimensional floating-point arrays representing key points), images (3-channel 480×480 pixels), task IDs (integer type), timestamps (floating-point type), frame indices, episode indices, global indices, and task indices. The dataset has a frame rate of 80 fps and provides a training split indexed as 0:100. Additionally, camera poses have been adjusted and image flipping has been performed on the data.
数据集概述
基本信息
- 名称: metaworld_mt50_push_v2_image
- 许可证: apache-2.0
- 任务类别: 机器人学 (robotics)
- 标签: LeRobot
数据集描述
- 创建工具: 使用 LeRobot 创建。
- 相机调整: 重新定位相机并翻转渲染图像,具体参数为
env.model.cam_pos[2] = [0.75, 0.075, 0.7]。
数据集结构
- 数据文件格式: Parquet 文件 (
data/*/*.parquet) - 元数据文件: meta/info.json 包含以下信息:
- 代码库版本: v2.0
- 机器人类型: metaworld
- 总剧集数: 100
- 总帧数: 6125
- 总任务数: 1
- 总视频数: 0
- 总块数: 1
- 块大小: 1000
- 帧率: 80 fps
- 分割: 训练集 (
train: 0:100) - 数据路径:
data/chunk-{episode_chunk:03d}/episode_{episode_index:06d}.parquet - 视频路径:
videos/chunk-{episode_chunk:03d}/{video_key}/episode_{episode_index:06d}.mp4
特征
- observation.state:
- 数据类型: float32
- 形状: [4]
- action:
- 数据类型: float32
- 形状: [4]
- 轴名称: ["x", "y", "z", "gripper"]
- next.reward:
- 数据类型: float32
- 形状: [1]
- next.success:
- 数据类型: bool
- 形状: [1]
- observation.environment_state:
- 数据类型: float32
- 形状: [39]
- 名称: ["keypoints"]
- observation.image:
- 数据类型: image
- 形状: [3, 480, 480]
- 名称: ["channels", "height", "width"]
- task_id:
- 数据类型: int16
- 形状: [1]
- timestamp:
- 数据类型: float32
- 形状: [1]
- frame_index:
- 数据类型: int64
- 形状: [1]
- episode_index:
- 数据类型: int64
- 形状: [1]
- index:
- 数据类型: int64
- 形状: [1]
- task_index:
- 数据类型: int64
- 形状: [1]
引用
- BibTeX: [More Information Needed]