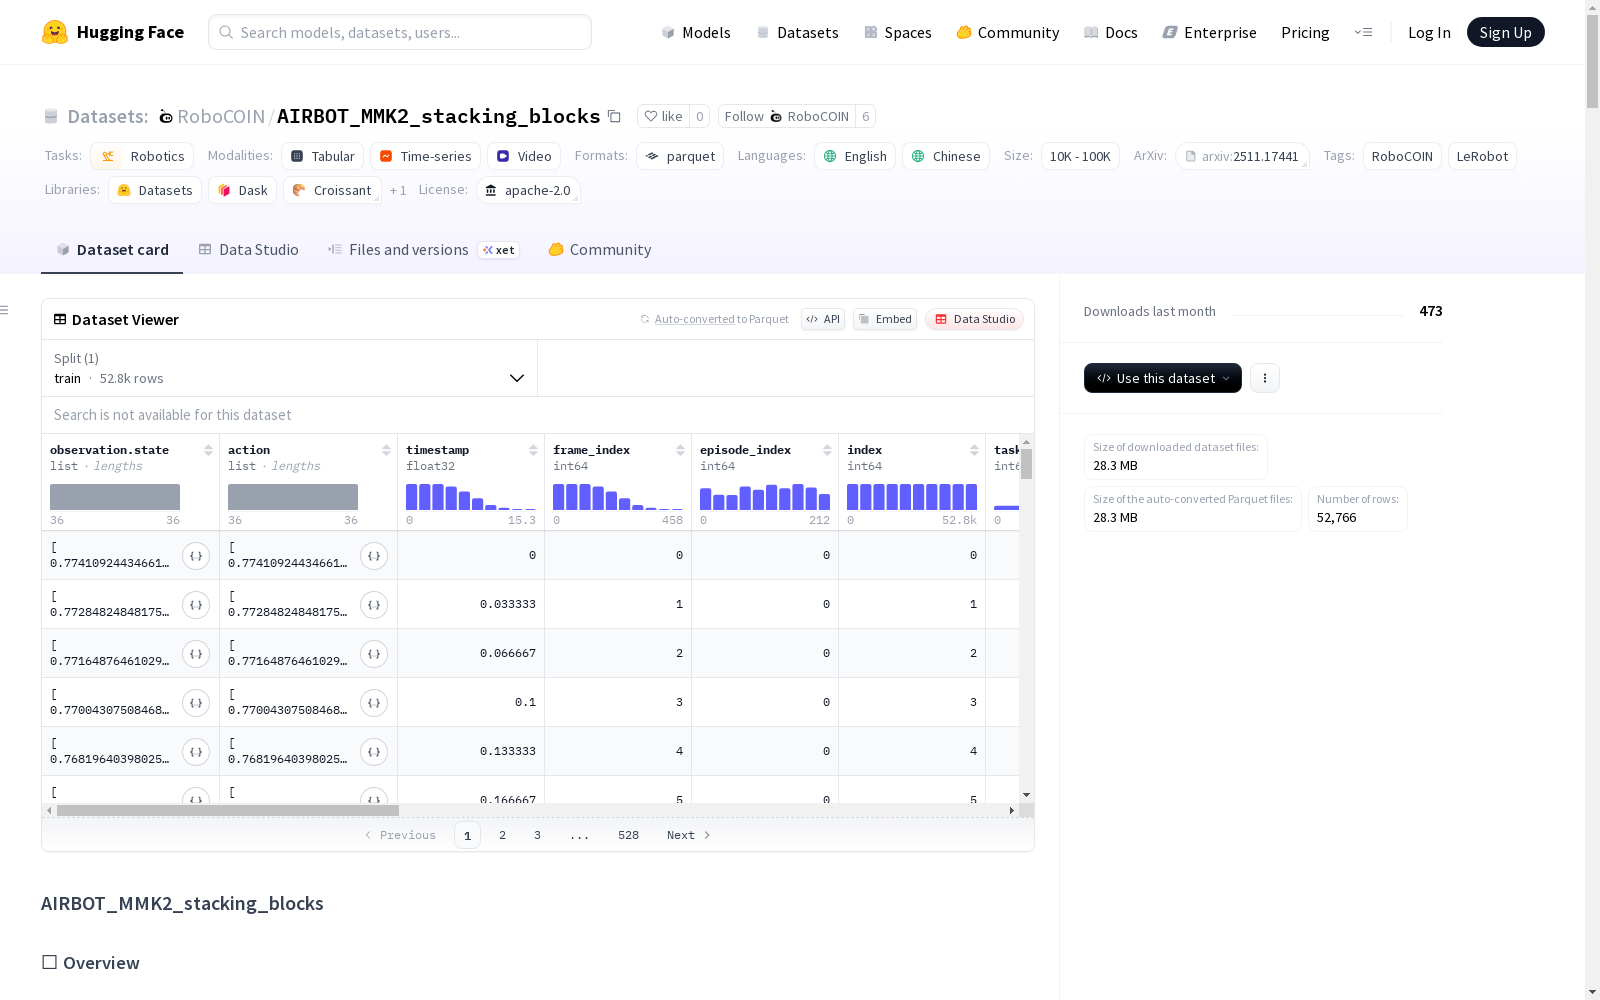
AIRBOT_MMK2_stacking_blocks
收藏资源简介:
这是一个基于LeRobot数据集的扩展格式数据集,完全兼容LeRobot。数据集使用AIRBOT_MMK2机器人,代码库版本为v2.1,末端执行器类型为五指手。数据集涵盖了家庭场景,包括抓取、捡起和放置等原子动作。数据集包含213个总剧集、52766帧、5个任务、852个视频和1个数据块,数据块大小为1000,帧率为30。数据集还包括丰富的注释,包括子任务分割、场景描述、末端执行器方向、速度、加速度等。数据集还包括抓取器模式、抓取器活动状态等注释。此外,数据集还包括末端执行器模拟姿态、抓取器开启刻度等附加特征。
This is an extended-format dataset based on the LeRobot dataset, which is fully compatible with LeRobot. The dataset utilizes the AIRBOT_MMK2 robot, with a codebase version of v2.1 and a five-fingered hand as its end-effector type. It covers household scenarios, including atomic actions such as grasping, picking up, and placing. The dataset contains 213 total episodes, 52766 frames, 5 tasks, 852 videos, and 1 data chunk with a size of 1000 and a frame rate of 30. It also provides rich annotations including subtask segmentation, scene descriptions, end-effector orientation, velocity, acceleration, and more. Additional annotations cover gripper mode and gripper active status. Furthermore, the dataset includes supplementary features such as simulated end-effector poses and gripper opening degrees.
AIRBOT_MMK2_stacking_blocks 数据集概述
基本信息
- 数据集名称: AIRBOT_MMK2_stacking_blocks
- 许可证: apache-2.0
- 支持语言: 英语、中文
- 任务类别: 机器人学
- 标签: RoboCOIN, LeRobot
- 规模类别: 10K-100K
技术规格
- 机器人类型: AIRBOT_MMK2
- 代码库版本: v2.1
- 末端执行器类型: five_finger_hand
- 场景类型: home
- 原子动作: grasp, pick, place
数据集统计
| 指标 | 数值 |
|---|---|
| 总情节数 | 213 |
| 总帧数 | 52766 |
| 总任务数 | 5 |
| 总视频数 | 852 |
| 总分块数 | 1 |
| 分块大小 | 1000 |
| 帧率 | 30 |
任务描述
主要任务
- 用一只手从桌子一侧拾取红色矩形块并放置在中心,然后用另一只手从另一侧拾取蓝色六边形木块并堆叠在红色块上
- 用一只手将大块从一侧移动到中心,用另一只手将小块堆叠在上面
- 用一只手从桌子上拾取一个块并放置在块堆上,然后用另一只手从桌子上拾取另一个块并放置在块堆上
- 用一只手从桌子一侧拾取蓝色立方体并放置在中间的黄色立方体上,然后用另一只手从另一侧拾取绿色立方体并放置在蓝色立方体上
- 用一只手从桌子上拾取蓝色立方体并放置在小桌子上,然后用另一只手从桌子上拾取红色立方体并放置在蓝色立方体上
子任务
包含25个不同的子任务,涵盖抓取和放置各种颜色和形状的积木操作
数据特征
视觉观察
- observation.images.cam_high_rgb: 视频,480×640×3,30fps,AV1编码
- observation.images.cam_left_wrist_rgb: 视频,480×640×3,30fps,AV1编码
- observation.images.cam_right_wrist_rgb: 视频,480×640×3,30fps,AV1编码
- observation.images.cam_third_view: 视频,480×640×3,30fps,AV1编码
状态和动作
- observation.state: float32,36维关节状态
- action: float32,36维动作命令
注释信息
- 子任务注释: 细粒度子任务分割和标注
- 场景注释: 语义场景分类和描述
- 末端执行器注释: 方向、速度、加速度分类
- 夹爪注释: 模式(开/关)、活动状态
运动特征
- 末端执行器仿真位姿: 6D位姿信息(状态和动作)
- 夹爪开合尺度: 连续夹爪开合测量(状态和动作)
数据组织
文件结构
- 数据路径模式:
data/chunk-{episode_chunk:03d}/episode_{episode_index:06d}.parquet - 视频路径模式:
videos/chunk-{episode_chunk:03d}/{video_key}/episode_{episode_index:06d}.mp4
数据分割
- 训练集: 情节0-212
作者和链接
贡献者
- RoboCOIN团队
相关链接
- 主页: https://flagopen.github.io/RoboCOIN/
- 论文: https://arxiv.org/abs/2511.17441
- 代码库: https://github.com/FlagOpen/RoboCOIN
- 问题反馈: https://github.com/FlagOpen/RoboCOIN/issues
引用信息
bibtex @article{robocoin, title={RoboCOIN: An Open-Sourced Bimanual Robotic Data Collection for Integrated Manipulation}, author={Shihan Wu, Xuecheng Liu, Shaoxuan Xie, Pengwei Wang, Xinghang Li, Bowen Yang, Zhe Li, Kai Zhu, Hongyu Wu, Yiheng Liu, Zhaoye Long, Yue Wang, Chong Liu, Dihan Wang, Ziqiang Ni, Xiang Yang, You Liu, Ruoxuan Feng, Runtian Xu, Lei Zhang, Denghang Huang, Chenghao Jin, Anlan Yin, Xinlong Wang, Zhenguo Sun, Junkai Zhao, Mengfei Du, Mingyu Cao, Xiansheng Chen, Hongyang Cheng, Xiaojie Zhang, Yankai Fu, Ning Chen, Cheng Chi, Sixiang Chen, Huaihai Lyu, Xiaoshuai Hao, Yequan Wang, Bo Lei, Dong Liu, Xi Yang, Yance Jiao, Tengfei Pan, Yunyan Zhang, Songjing Wang, Ziqian Zhang, Xu Liu, Ji Zhang, Caowei Meng, Zhizheng Zhang, Jiyang Gao, Song Wang, Xiaokun Leng, Zhiqiang Xie, Zhenzhen Zhou, Peng Huang, Wu Yang, Yandong Guo, Yichao Zhu, Suibing Zheng, Hao Cheng, Xinmin Ding, Yang Yue, Huanqian Wang, Chi Chen, Jingrui Pang, YuXi Qian, Haoran Geng, Lianli Gao, Haiyuan Li, Bin Fang, Gao Huang, Yaodong Yang, Hao Dong, He Wang, Hang Zhao, Yadong Mu, Di Hu, Hao Zhao, Tiejun Huang, Shanghang Zhang, Yonghua Lin, Zhongyuan Wang and Guocai Yao}, journal={arXiv preprint arXiv:2511.17441}, url = {https://arxiv.org/abs/2511.17441}, year={2025} }