
EgoEVHands
收藏资源简介:
EgoEVHands是由浙江大学等机构创建的首个大规模真实世界立体事件相机数据集,专为第一人称手部感知设计。该数据集包含5,419个标注序列,涵盖38种手势类别,数据来源于同步立体事件流,并提供了高保真的2D/3D手部关键点标注与分割掩码。其构建过程通过自动化标注流程实现,结合了红外图像关键点检测与分割技术,确保了在多变光照条件下的数据精度。该数据集主要应用于增强/虚拟现实、人机交互与机器人领域,旨在解决传统RGB相机在动态范围、运动模糊方面的局限,以及单目事件方法在深度模糊和缺乏真实世界立体数据方面的挑战。
EgoEVHands is the first large-scale real-world stereo event camera dataset developed by Zhejiang University and other institutions, tailored specifically for first-person hand perception tasks. It contains 5,419 annotated sequences spanning 38 gesture categories, derived from synchronized stereo event streams, and provides high-fidelity 2D/3D hand keypoint annotations as well as segmentation masks. The dataset was constructed via an automated annotation pipeline that integrates infrared image keypoint detection and segmentation technologies, ensuring data precision across varying lighting conditions. Primarily intended for applications in augmented reality, virtual reality, human-computer interaction and robotics, this dataset aims to mitigate the limitations of conventional RGB cameras in dynamic range and motion blur, as well as address the core challenges of monocular event-based methods, including depth ambiguity and the scarcity of real-world stereo event datasets.
根据您提供的数据集详情页面信息,以下是对该数据集的概述:
数据集概述
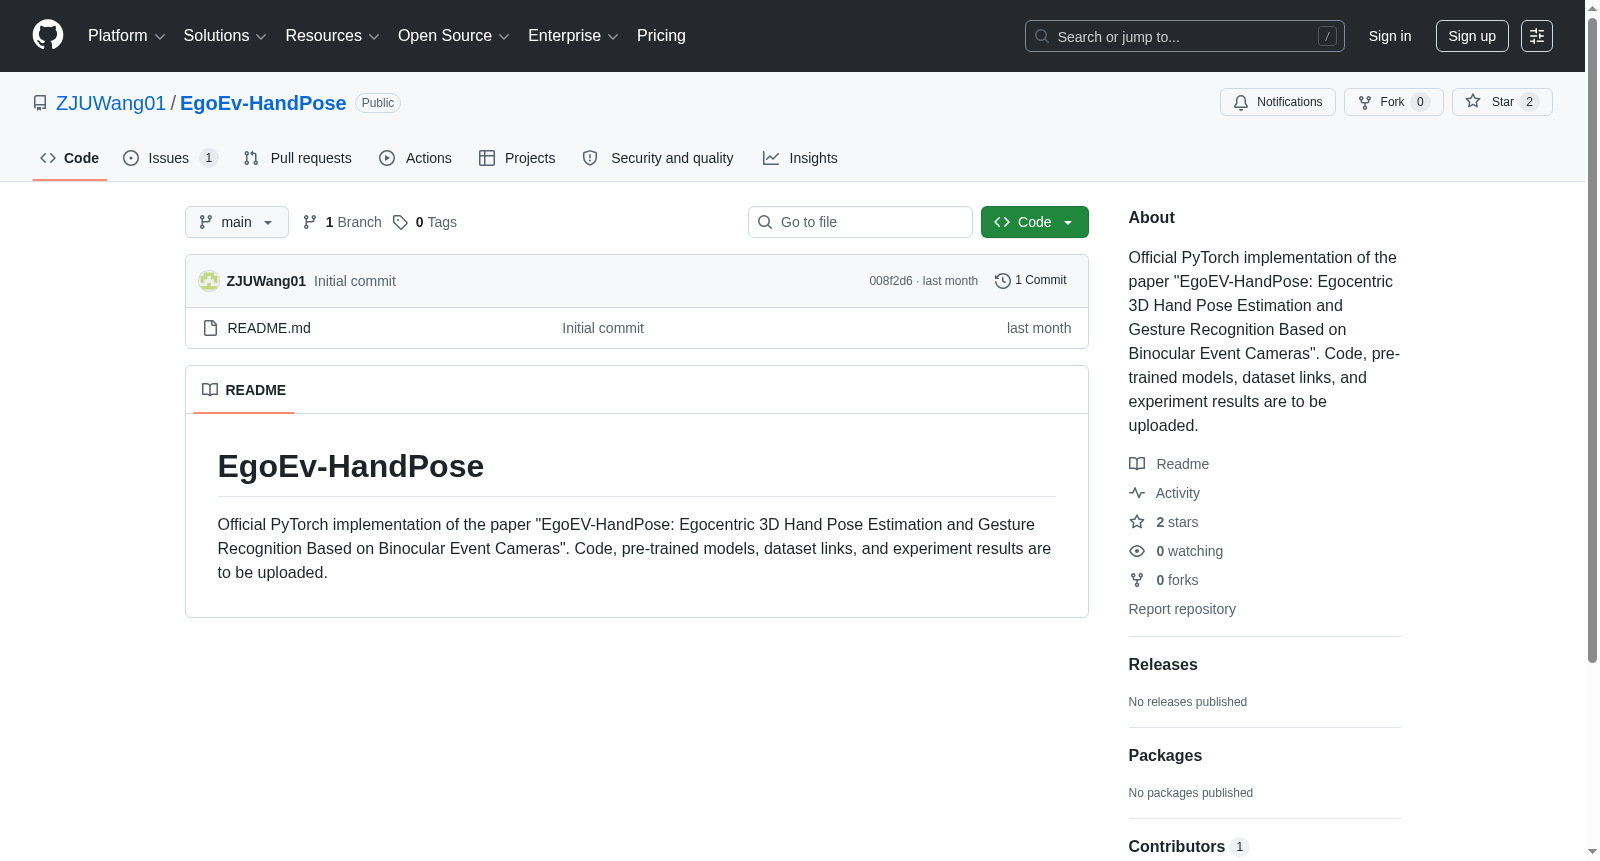
- 数据集名称:EgoEv-HandPose
- 论文标题:EgoEV-HandPose: Egocentric 3D Hand Pose Estimation and Gesture Recognition Based on Binocular Event Cameras
- 任务领域:基于双眼事件相机的自我中心3D手部姿态估计与手势识别
- 数据来源:双眼事件相机采集的自我中心视角数据
- 当前状态:代码、预训练模型、数据集链接及实验成果尚未上传,计划后续公开
- 实现框架:基于PyTorch实现
- 1EgoEV-HandPose: Egocentric 3D Hand Pose Estimation and Gesture Recognition with Stereo Event Cameras浙江大学·国家光学仪器工程技术研究中心; 湖南大学·人工智能与机器人学院·机器人视觉感知与控制技术国家工程研究中心; 蚂蚁集团股份有限公司; 舜宇光学科技中央研究院 · 2026年


