LIBERO-3D
收藏资源简介:
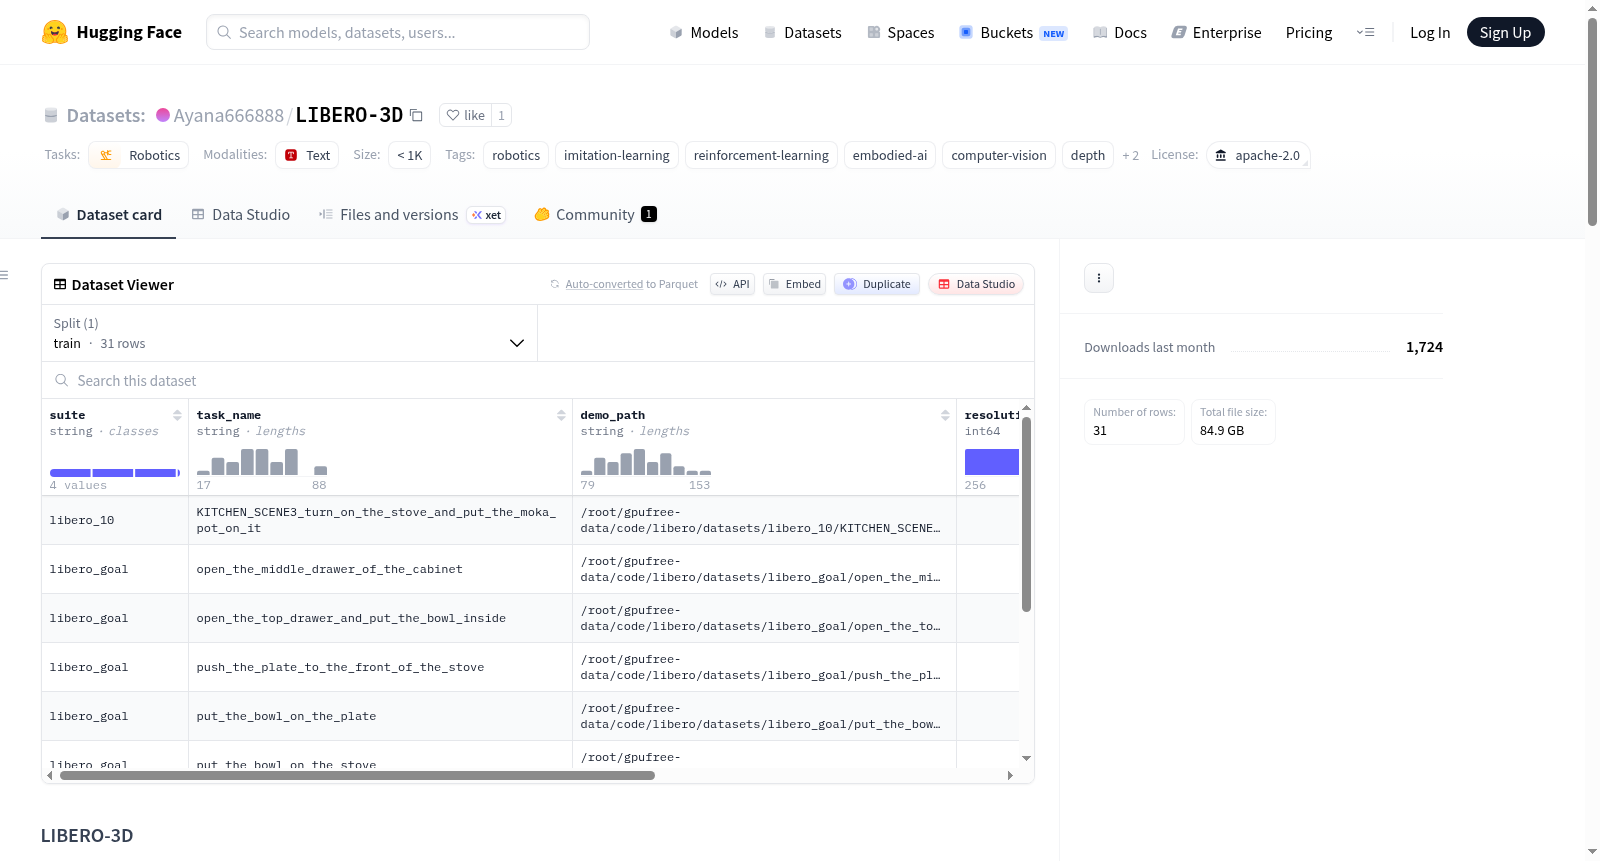
LIBERO-3D是一个专为3D感知机器人学习设计的数据集,基于原始LIBERO任务套件进行封装和重新组织。数据集将每个演示轨迹转换为以每集为单位的.npz文件,包含多模态数据,如RGB图像、深度图、相机参数(包括内参和外参)、分割图、机器人状态和控制动作。它包含四个任务套件:libero_goal(10个目标条件操作任务)、libero_object(10个以物体为中心的拾放任务)、libero_spatial(10个空间关系操作任务)以及libero_10(10个来自LIBERO-10套件的长时程任务),每个套件有10个任务,每个任务包含50个演示片段,总计40个任务和2000个片段。每个数据片段(data.npz)存储轨迹对齐的数组,具体包括:机器人状态(形状(T, 8))、控制动作(形状(T, 7))、静态相机RGB帧(形状(T, 256, 256, 3))、静态相机深度帧(形状(T, 256, 256))、腕部相机RGB帧(形状(T, 256, 256, 3))、腕部相机深度帧(形状(T, 256, 256))、腕部相机内参(形状(T, 3, 3))、腕部相机外参(形状(T, 4, 4))以及腕部分割图(形状(T, 256, 256, 2))。此外,任务级别的metadata.json文件记录了套件名称、任务名称、原始演示路径、图像分辨率、状态语义、相机校准字段以及每集的步数和张量形状。该数据集源自LIBERO基准数据集,经过优化以适应下游3D学习流程,采用Apache-2.0许可证,主要用于文件托管和下载,数据以二进制.npz格式存储,不适用于浏览器内预览。
LIBERO-3D is a processed and packaged LIBERO demonstration dataset for 3D-aware robot learning. It retains the original LIBERO task suites while converting each trajectory into per-episode .npz files containing multimodal data such as RGB images, depth maps, camera parameters, segmentation maps, states, and actions. The dataset includes four task suites: libero_goal (10 goal-conditioned manipulation tasks), libero_object (10 object-centric pick-and-place tasks), libero_spatial (10 spatial relation manipulation tasks), and libero_10 (10 long-horizon tasks from the LIBERO-10 suite). Each suite contains 10 tasks, with 50 demonstration episodes per task, totaling 40 tasks and 2000 episodes. Each data episode (data.npz) stores trajectory-aligned arrays, specifically: robot state (shape (T, 8)), control actions (shape (T, 7)), static camera RGB frames (agentview_rgb, shape (T, 256, 256, 3)), static camera depth frames (agentview_depth, shape (T, 256, 256)), wrist camera RGB frames (wrist_rgb, shape (T, 256, 256, 3)), wrist camera depth frames (wrist_depth, shape (T, 256, 256)), wrist camera intrinsic parameters (wrist_intrinsic, shape (T, 3, 3)), wrist camera extrinsic parameters (wrist_extrinsic, shape (T, 4, 4)), and wrist segmentation maps (wrist_segmentation, shape (T, 256, 256, 2)). Task-level metadata.json files also record suite name, task name, original demonstration path, image resolution, state semantics, camera calibration fields, and per-episode step counts and tensor shapes. The dataset is derived from the LIBERO benchmark dataset and reorganized for downstream 3D learning workflows. It is licensed under Apache-2.0. Note that this repository is primarily for file hosting and dataset download, not for in-browser preview, and data is stored in binary .npz format rather than tabular data.