
DexGraspNet
收藏资源简介:
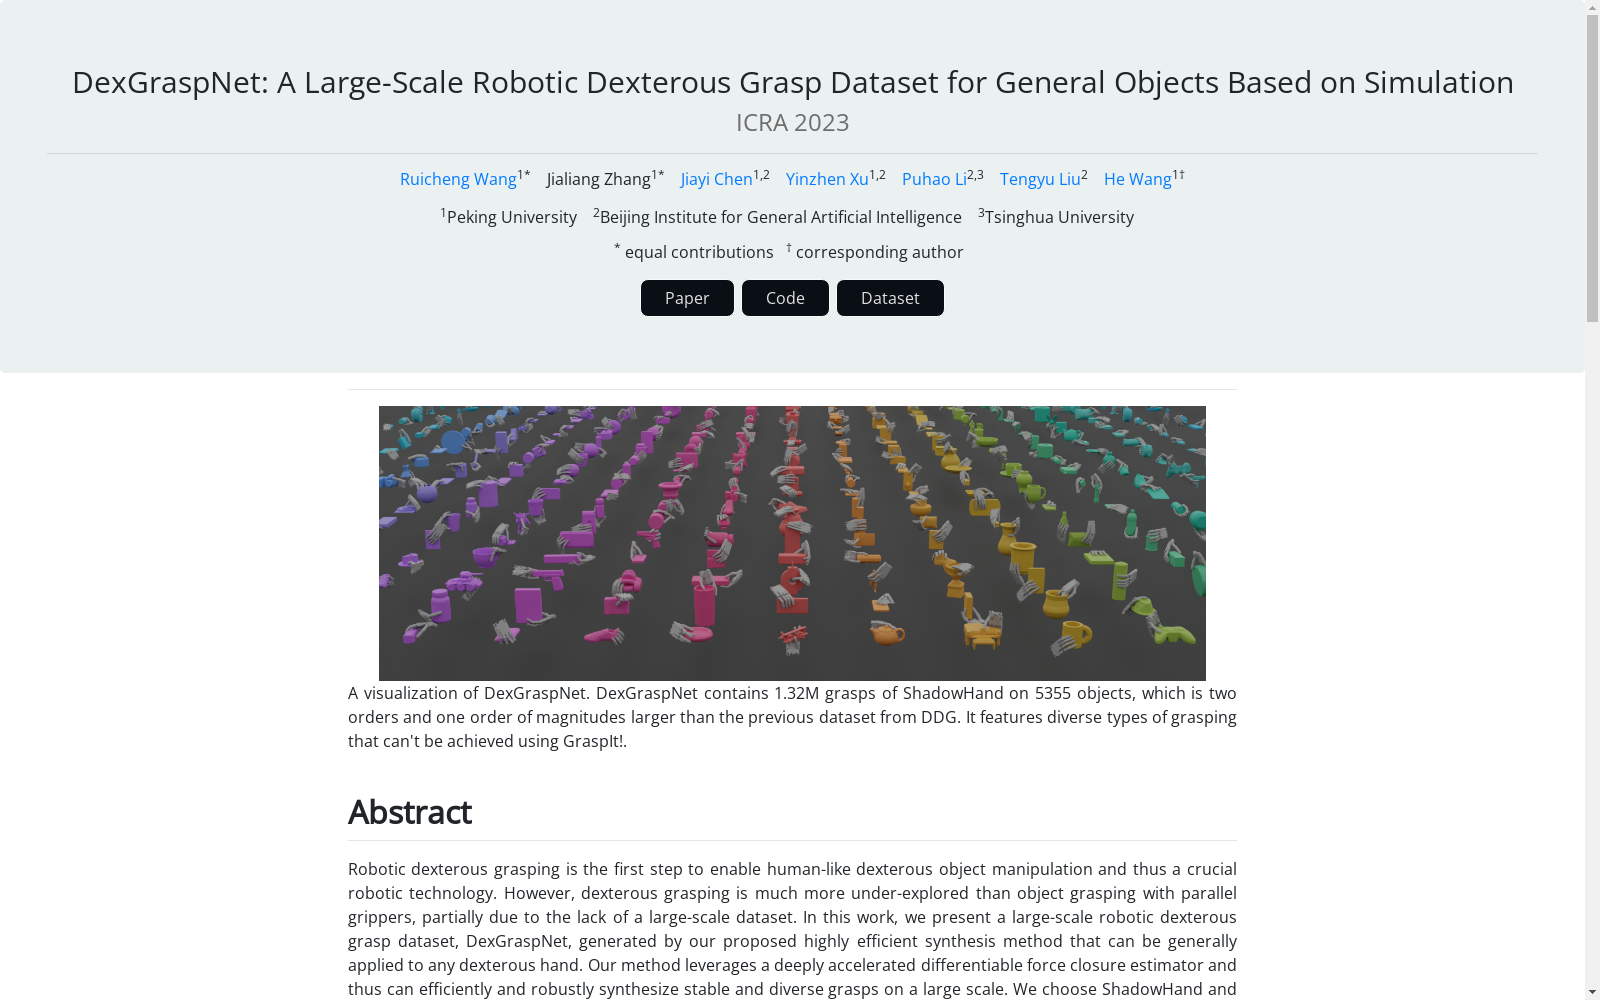
DexGraspNet是由北京大学等机构创建的大规模机器人灵巧抓取数据集,基于模拟技术生成。该数据集包含132万个针对5355个对象的抓取动作,覆盖超过133个对象类别,每个对象实例包含超过200种多样化的抓取动作。数据集的创建过程利用了一种高效的合成方法,通过深度加速的可微力闭合估计器,能够大规模地高效且稳健地合成稳定多样的抓取动作。所有抓取动作均通过Isaac Gym模拟器验证,确保物理稳定性。DexGraspNet的应用领域广泛,旨在解决机器人灵巧抓取技术中的关键问题,提高抓取算法的性能和多样性。
DexGraspNet is a large-scale robotic dexterous grasping dataset developed by Peking University and other institutions, generated via simulation technology. This dataset contains 1.32 million grasping motions targeting 5355 objects, covering over 133 object categories, with each object instance including more than 200 diverse grasping motions. The dataset construction adopts an efficient synthesis approach that leverages a depth-accelerated differentiable force closure estimator, enabling efficient, robust and large-scale synthesis of stable and diverse grasping motions. All grasping motions are validated using the Isaac Gym simulator to guarantee physical stability. DexGraspNet has a wide range of application scenarios, aiming to address key challenges in robotic dexterous grasping technology and improve the performance and diversity of grasping algorithms.
- 1DexGraspNet: A Large-Scale Robotic Dexterous Grasp Dataset for General Objects Based on Simulation北京大学 · 2023年


