lilkm/pack_easter_eggs_into_basket
收藏资源简介:
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). <a class="flex" href="https://huggingface.co/spaces/lerobot/visualize_dataset?path=lilkm/pack_easter_eggs_into_basket"> <img class="block dark:hidden" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl.svg"/> <img class="hidden dark:block" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl-dark.svg"/> </a> ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "fps": 20, "features": { "action": { "dtype": "float32", "shape": [ 14 ], "fps": 20 }, "observation.state": { "dtype": "float32", "shape": [ 14 ], "fps": 20 }, "observation.velocity": { "dtype": "float32", "shape": [ 14 ], "fps": 20 }, "observation.effort": { "dtype": "float32", "shape": [ 14 ], "fps": 20 }, "observation.eef_6d_pose": { "dtype": "float32", "shape": [ 12 ], "fps": 20 }, "observation.images.front": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.fps": 20.0, "video.height": 480, "video.width": 640, "video.channels": 3, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "has_audio": false } }, "observation.images.left_wrist": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.fps": 20.0, "video.height": 480, "video.width": 640, "video.channels": 3, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "has_audio": false } }, "observation.images.right_wrist": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.fps": 20.0, "video.height": 480, "video.width": 640, "video.channels": 3, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "has_audio": false } }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null, "fps": 20 }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null, "fps": 20 }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null, "fps": 20 }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null, "fps": 20 }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null, "fps": 20 } }, "total_episodes": 80, "total_frames": 54874, "total_tasks": 1, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 200, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "robot_type": "arx5", "splits": { "train": "0:80" } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
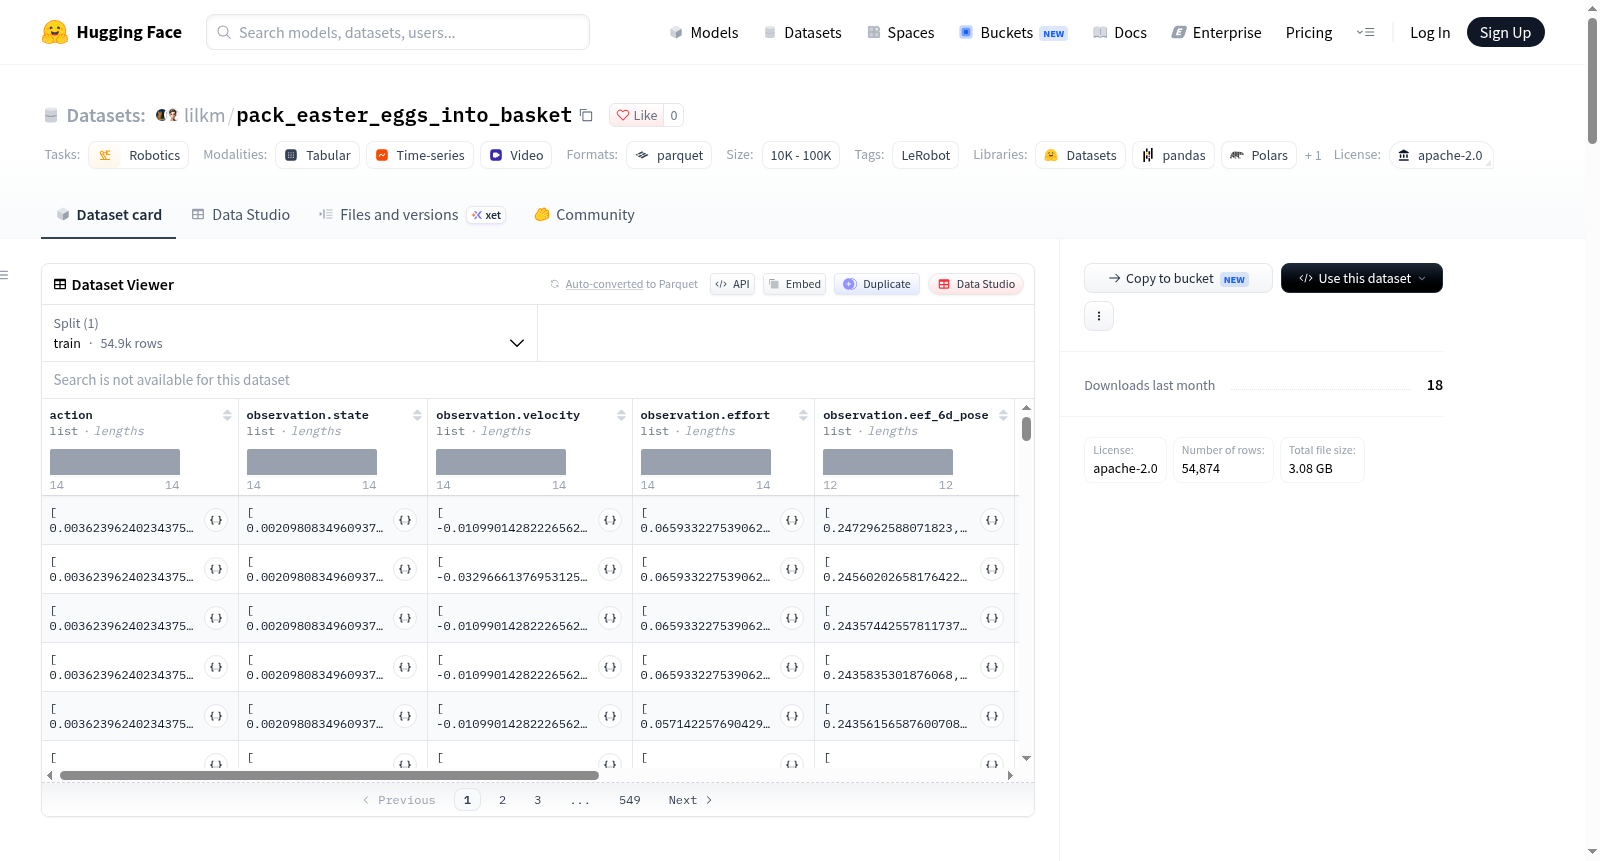
This dataset was created using LeRobot and is a robotics dataset designed for training and evaluating robot tasks, specifically involving the operation of packing Easter eggs into a basket. It contains a total of 80 episodes, with 54874 frames at a frame rate of 20 fps. The features include action (14-dimensional float array), observation.state (14-dimensional float array), observation.velocity (14-dimensional float array), observation.effort (14-dimensional float array), observation.eef_6d_pose (12-dimensional float array), and video observations from front, left wrist, and right wrist cameras (resolution 480x640, 3 channels, AV1 codec). Additionally, metadata such as timestamp, frame index, episode index, index, and task index are included. The dataset is licensed under Apache 2.0, uses the arx5 robot type, and is split into training set (0:80). Data is stored in parquet format, with a total data file size of 100 MB and video file size of 200 MB.