RoboSet
收藏资源简介:
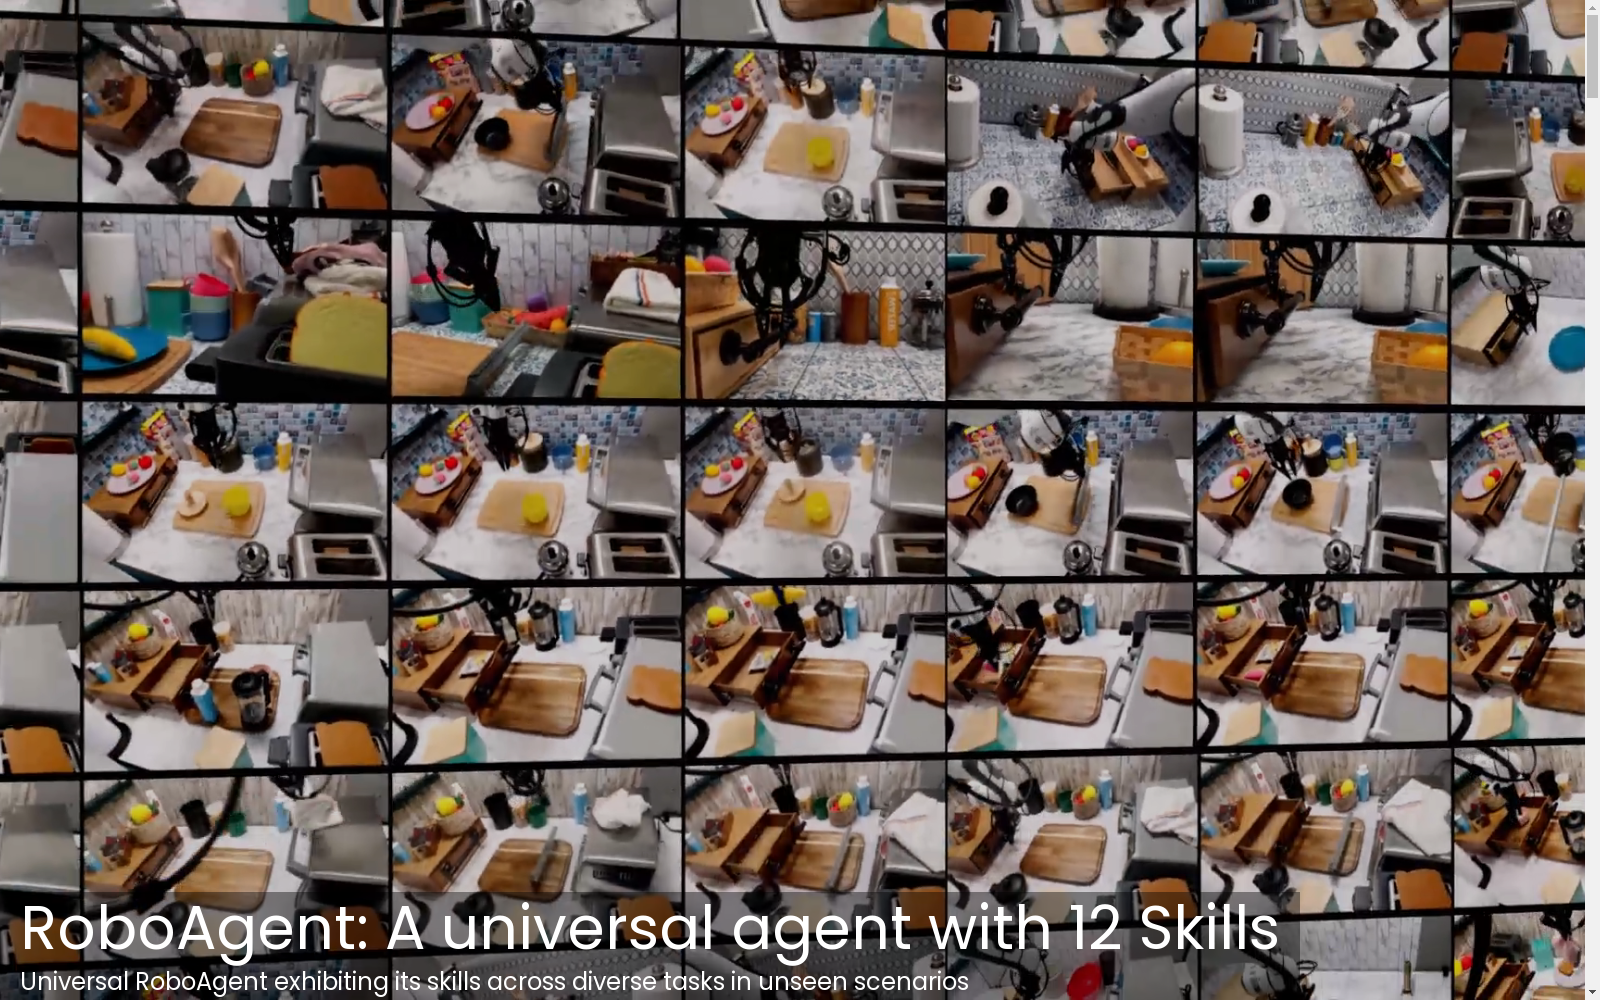
RoboSet 是一个大规模开源机器人操作数据集,由卡内基梅隆大学和 Meta AI 研究团队创建。该数据集包含 7500 条通过人类远程操作收集的机器人轨迹,涵盖了 12 种不同的操作技能,如滑动、开合、抓取、放置等,这些技能在 38 个任务和 10 个不同的厨房场景中得以体现。数据集中的每个技能在多种物体上进行了实例化,以确保行为的多样性。此外,RoboSet 还通过语义增强技术对数据进行扩充,以帮助模型更好地泛化到新的场景和任务中。
RoboSet is a large-scale open-source robotic manipulation dataset created by the research teams from Carnegie Mellon University and Meta AI. This dataset contains 7,500 robotic trajectories collected via human teleoperation, covering 12 distinct manipulation skills such as sliding, opening and closing, grasping, placing, etc. These skills are demonstrated across 38 tasks and 10 distinct kitchen environments. Each skill in the dataset is instantiated on various objects to ensure behavioral diversity. Additionally, RoboSet augments its data through semantic enhancement techniques to help models better generalize to novel scenarios and tasks.