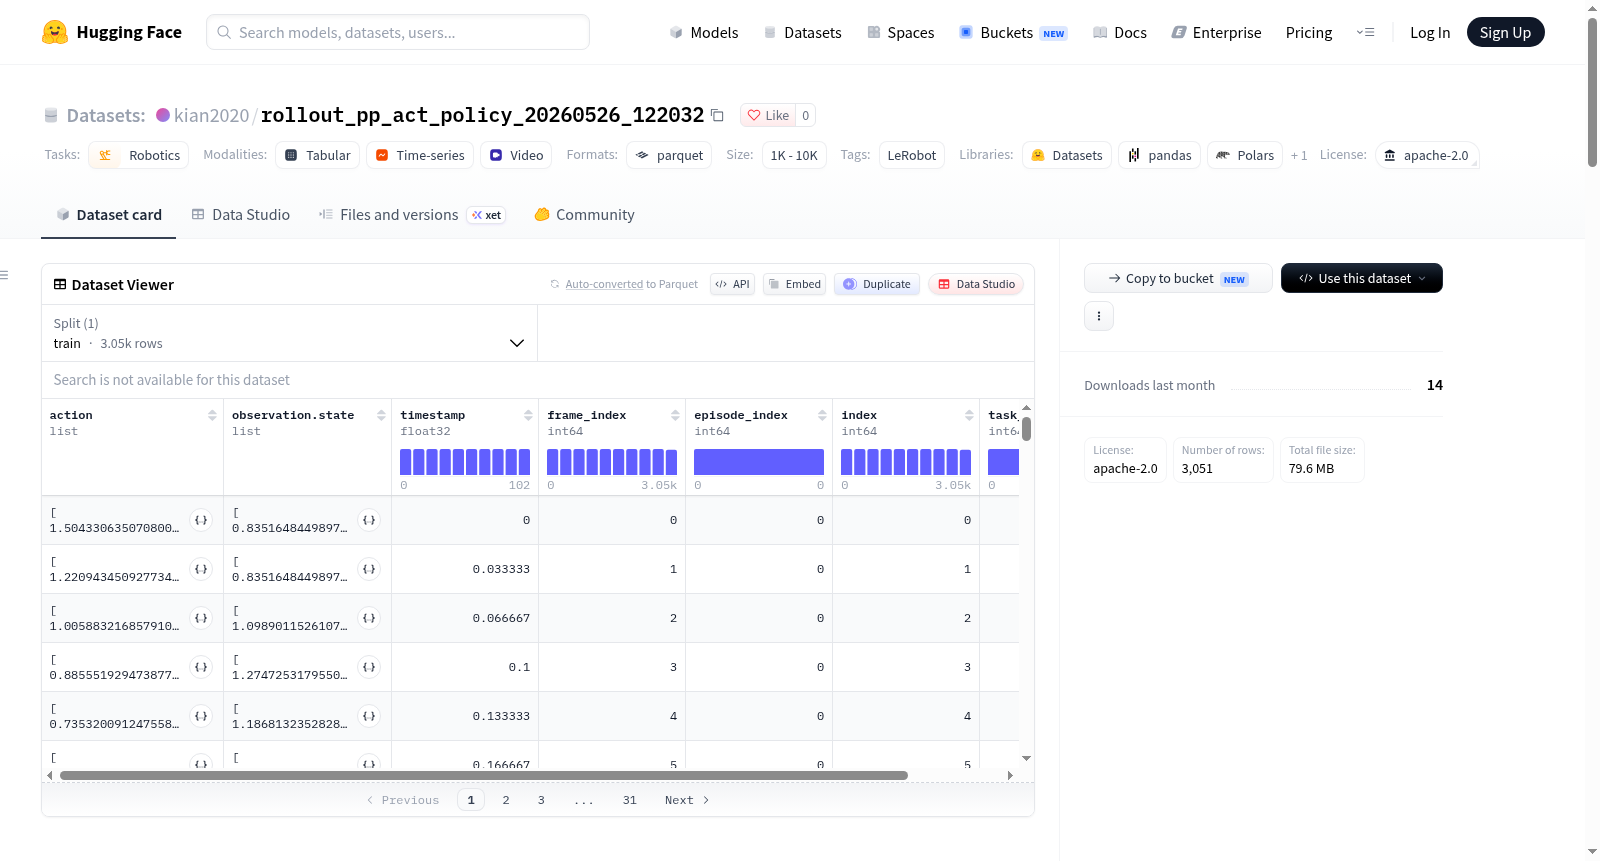
kian2020/rollout_pp_act_policy_20260526_122032
收藏资源简介:
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). <a class="flex" href="https://huggingface.co/spaces/lerobot/visualize_dataset?path=kian2020/rollout_pp_act_policy_20260526_122032"> <img class="block dark:hidden" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl.svg"/> <img class="hidden dark:block" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl-dark.svg"/> </a> ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "fps": 30, "features": { "action": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.state": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.images.front": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false } }, "observation.images.top": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false } }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } }, "total_episodes": 1, "total_frames": 3051, "total_tasks": 1, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 200, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "robot_type": "so_follower", "splits": { "train": "0:1" } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
This dataset is a robotics dataset created using LeRobot, containing one episode of robot operation data with a total of 3051 frames. The dataset features include actions (6 float values corresponding to shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, and gripper positions), observation states (same 6 float values as actions), front and top view images (video format, resolution 480x640, 3 channels, 30fps), timestamp, frame index, episode index, index, and task index. The data is stored in Parquet file format, and videos are stored in MP4 format. The robot type is so_follower, and the dataset is primarily used for training and evaluating robot policies.